Starting viewport
Unitree Robotics · humanoid
Unitree H1-2
Revised H1 with 7-DOF arms, added ankle DOF and higher arm payload, trading top speed for manipulation.
Frames · Unitree H1-2
3 items · credit and license on each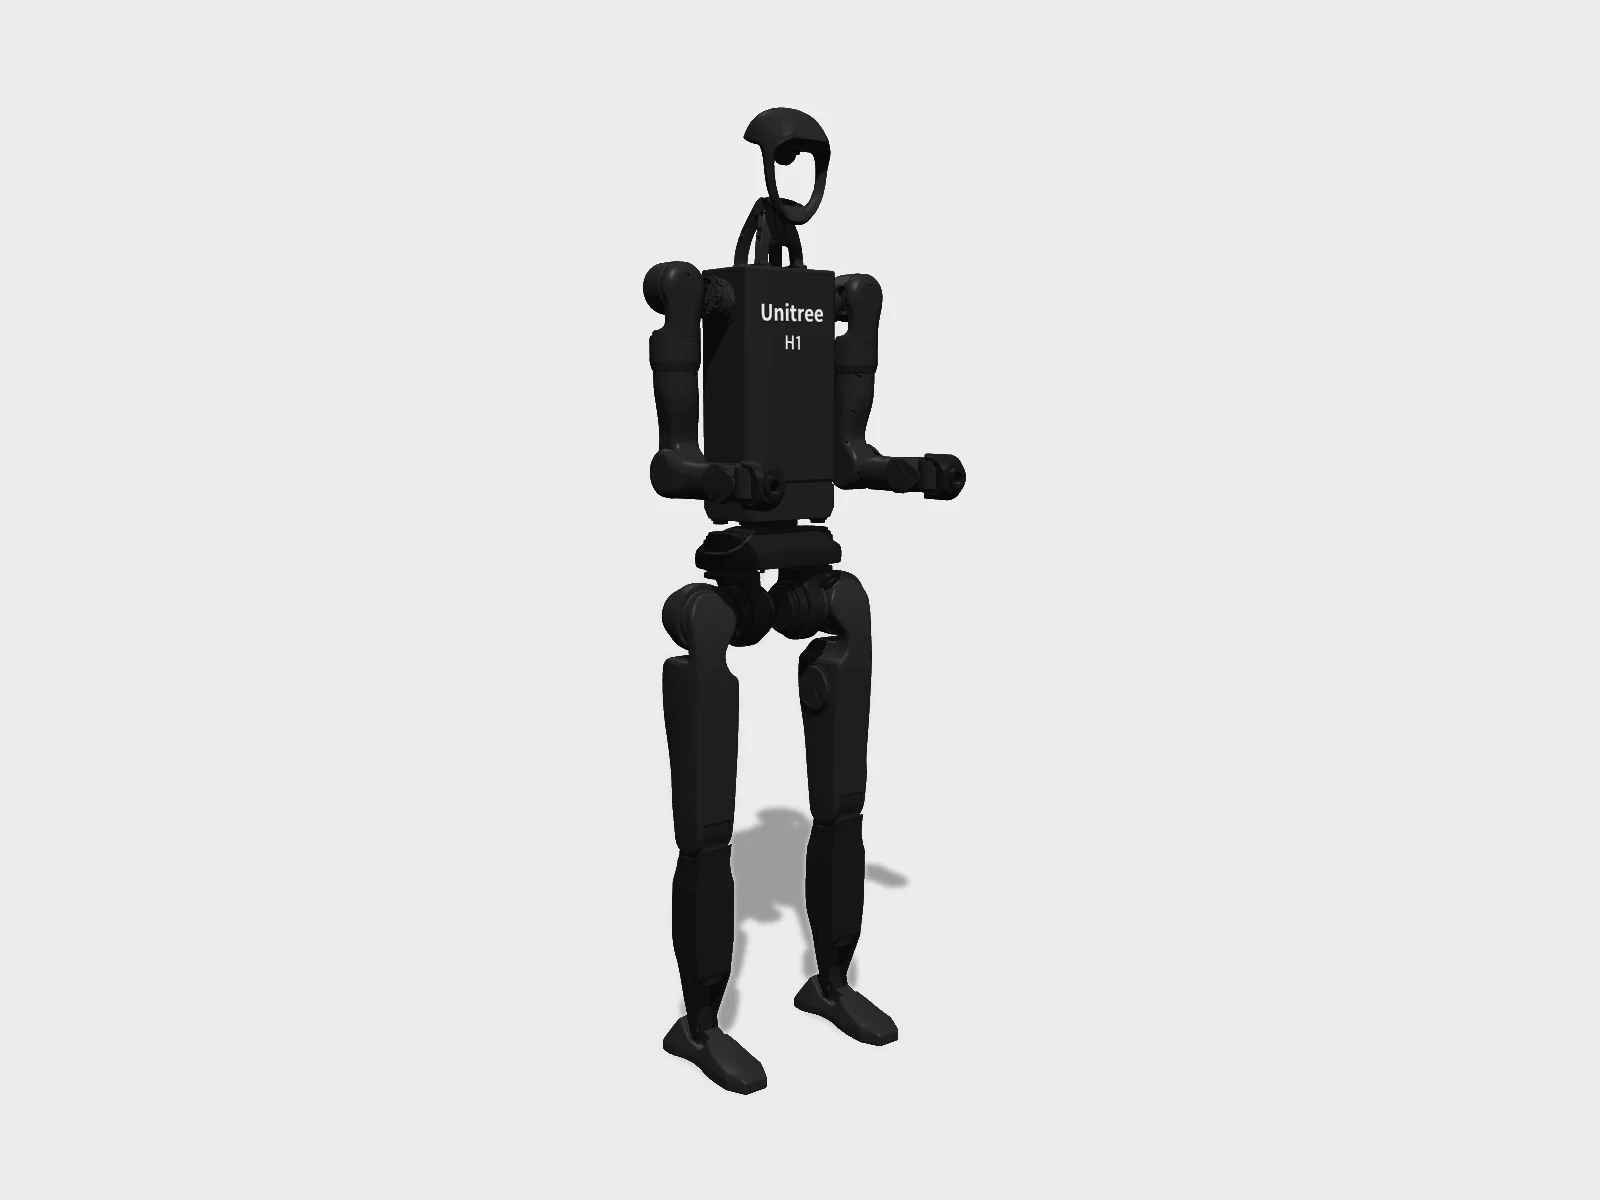
Studio render of the published MJCF, the model's zero pose. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from unitreerobotics/unitree_mujoco (BSD-3-Clause) · Hyperspawn render · source 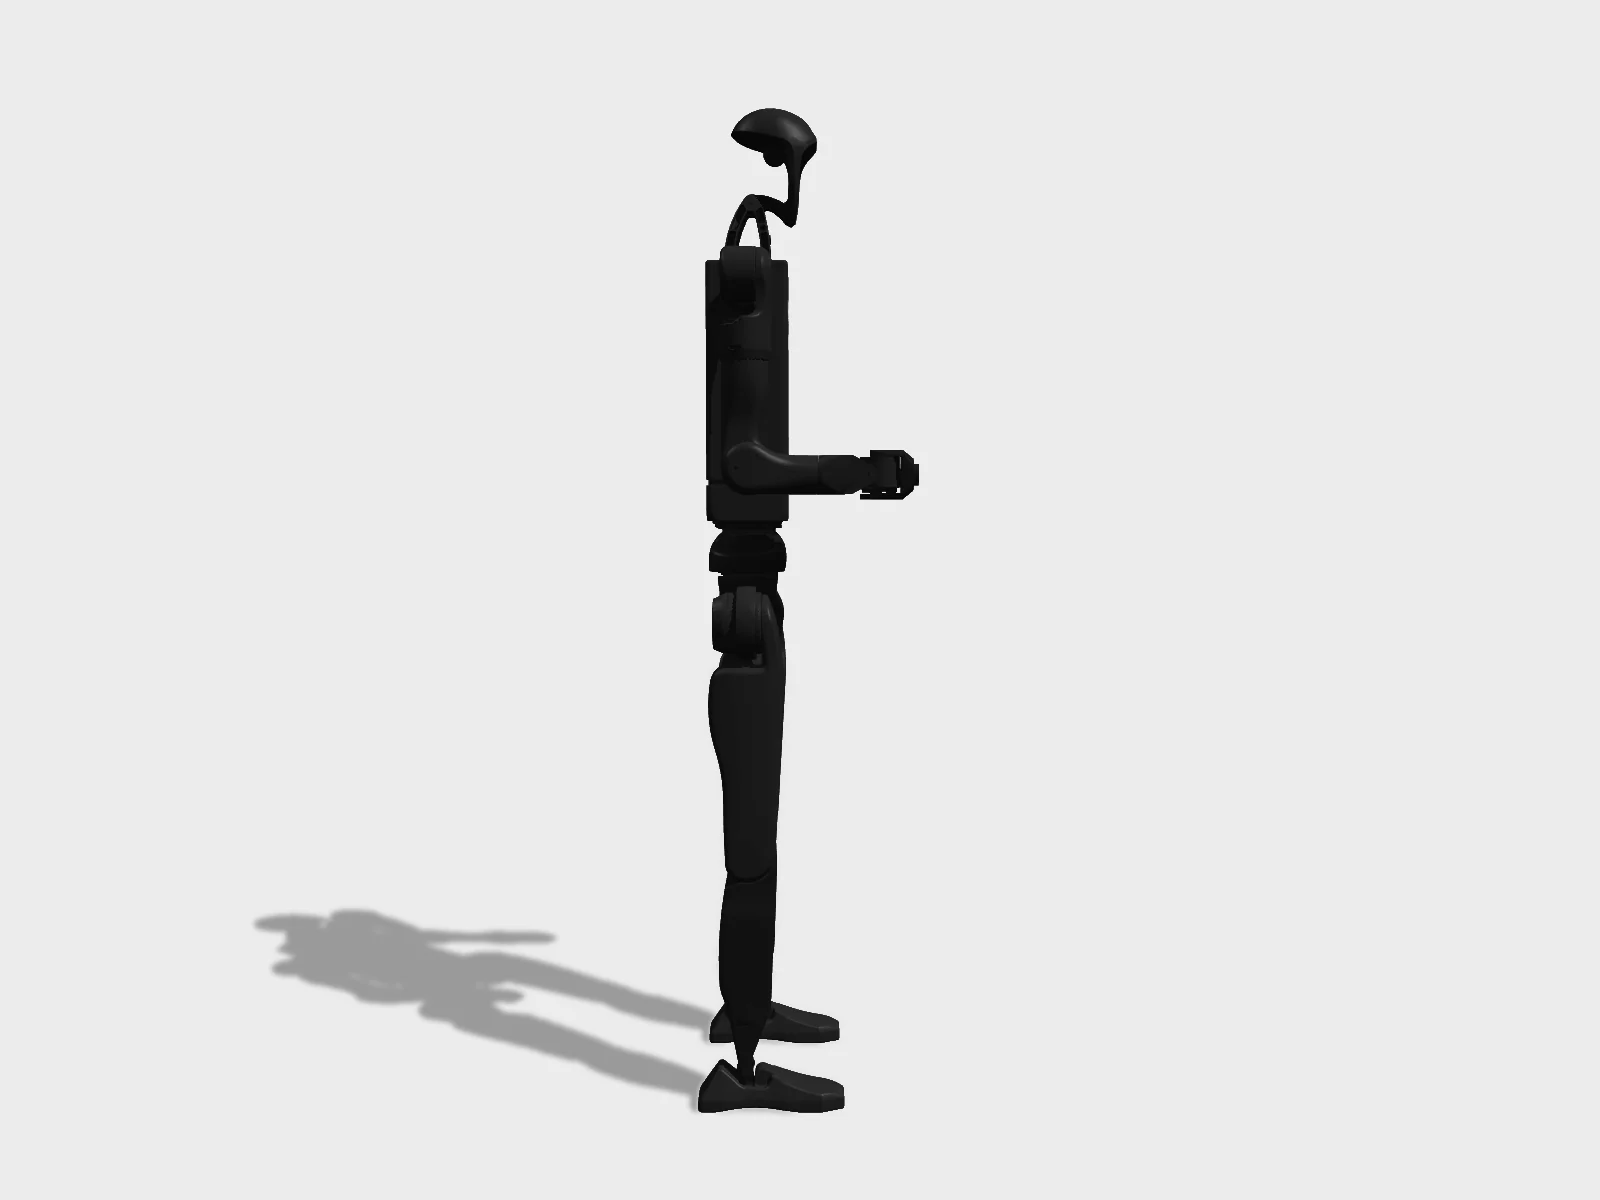
Side view of the same MJCF render, the model's zero pose.Rendered by Hyperspawn from unitreerobotics/unitree_mujoco (BSD-3-Clause) · Hyperspawn render · source 4 s turntable of the MJCF studio render.Rendered by Hyperspawn from unitreerobotics/unitree_mujoco (BSD-3-Clause) · Hyperspawn render · source
Provenance
- Model
- Unitree H1-2
- Commit
- 1eb6642e3f3f
- Entry
- unitree_robots/h1_2/h1_2_handless.xml
- Files
- 29 · 26 MB, fetched from raw.githubusercontent.com, cached in your browser
- License
- BSD-3-Clause
- Engine
- MuJoCo 3.14.0, official WebAssembly build · three.js renderer
- Controller
- PD hold on the stand keyframe with an ankle-strategy tilt term; not a learned policy
- Note
- unitree_mujoco's handless H1-2, torque-driven.
Policies listed for Unitree H1-2
No published policy we can replay yet.
Nothing is playing a trained controller in the viewport above. What you see is a PD hold on the stand pose, computed in your tab. A policy plays here when a checkpoint is published with an obs/action contract we can reproduce exactly in MuJoCo, and it passes a 30 s walk test in the tab.
Set up a training runTrain on GPUs
mjlab ships no stock task for Unitree H1-2. The training page gives you the pinned model and the steps to write a robot config.