Starting viewport
Stanford / Columbia / Toyota Research Institute · gripper
UMI Gripper (Universal Manipulation Interface)
Handheld, trigger-activated 3D-printed parallel-jaw gripper with a GoPro and side mirrors for in-the-wild demonstration collection, with policies deployable on robot-mounted grippers.
Frames · UMI Gripper (Universal Manipulation Interface)
4 items · credit and license on each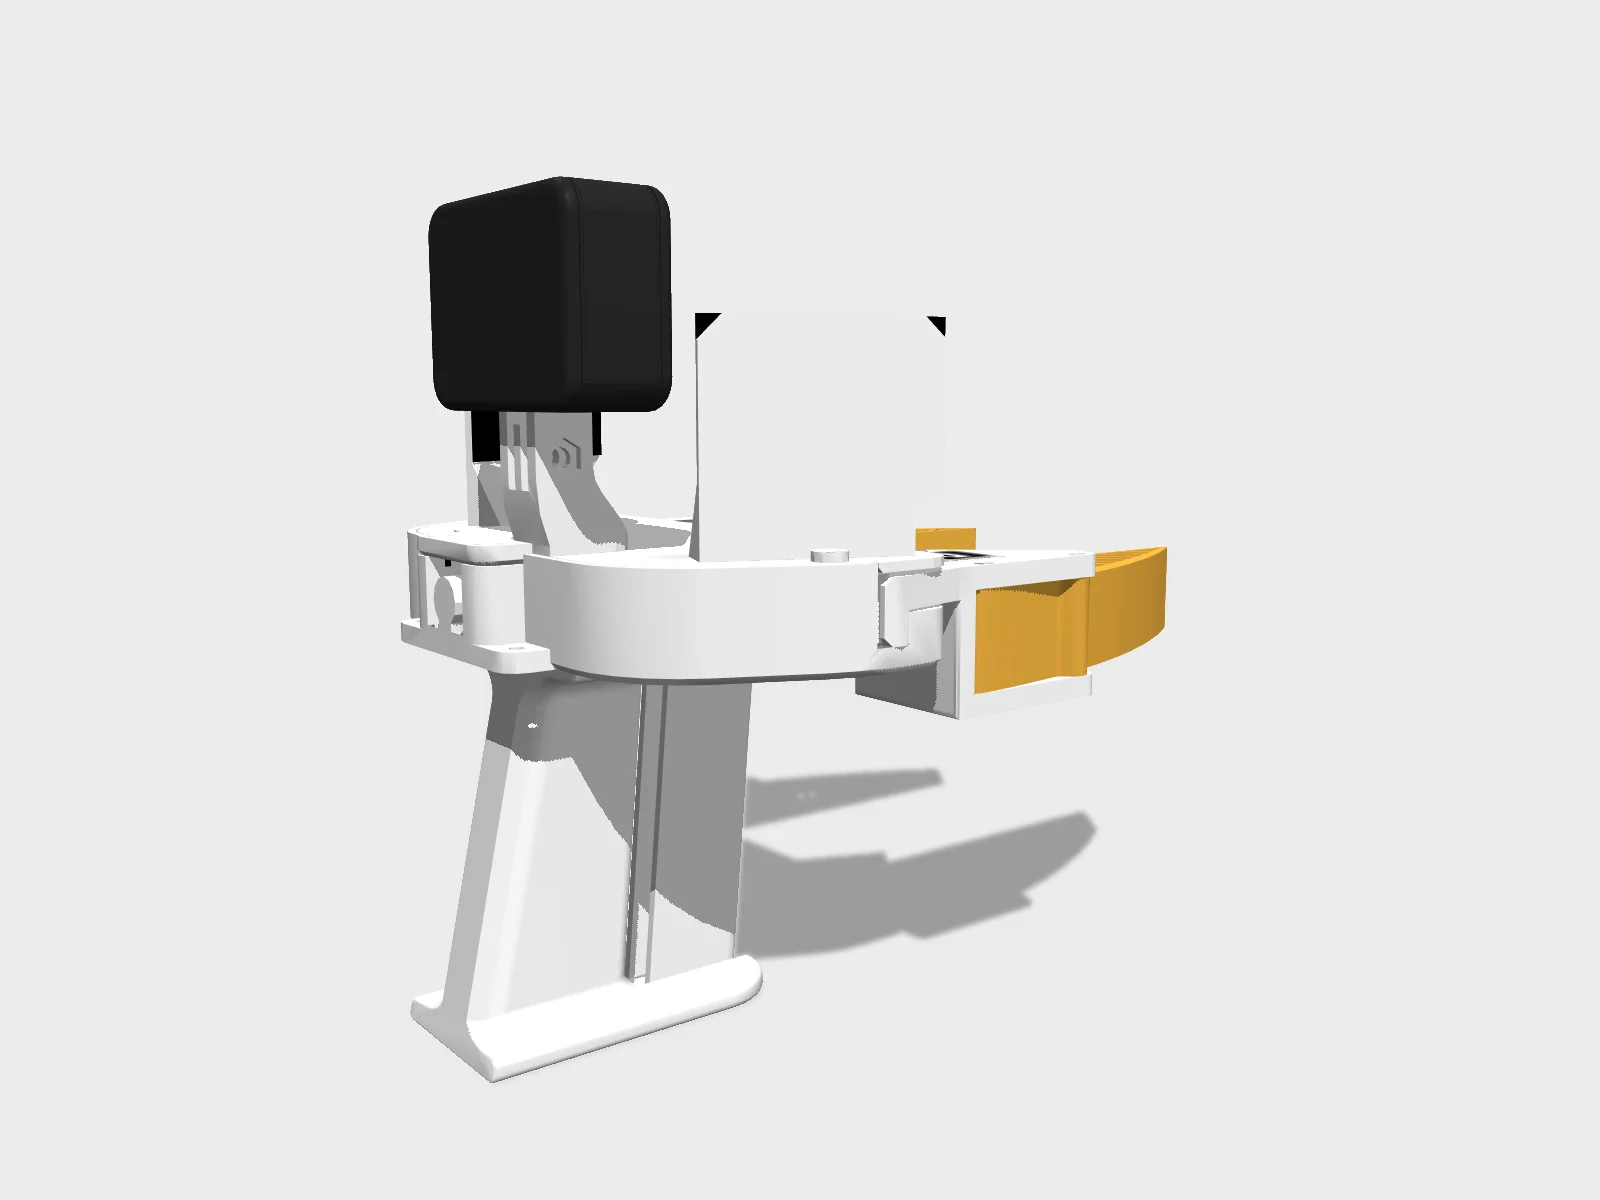
Studio render of the published MJCF, the model's zero pose. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from mujoco_menagerie/umi_gripper (MIT) · Hyperspawn render · source 
Side view of the same MJCF render, the model's zero pose.Rendered by Hyperspawn from mujoco_menagerie/umi_gripper (MIT) · Hyperspawn render · source 4 s turntable of the MJCF studio render.Rendered by Hyperspawn from mujoco_menagerie/umi_gripper (MIT) · Hyperspawn render · source UMI - 3D Printing TutorialRobotics & Embodied Artificial Intelligence Lab · official embed · source
Provenance
No browser-ready model packaged yet.
The description is public, but nobody has pinned a commit and checked it compiles in MuJoCo WASM. Clone it and drop the folder on the viewport above (MJCF, or URDF with STL/OBJ meshes). Files stay in your tab.
Policies listed for UMI Gripper (Universal Manipulation Interface)
- source
In-the-wild cup arrangement (rotate espresso cup, place on saucer)
Diffusion Policy (UMI), fine-tuned CLIP ViT-L backbone · not replayed in the tab
Train on GPUs
mjlab ships no stock task for UMI Gripper (Universal Manipulation Interface). The training page gives you the pinned model and the steps to write a robot config.