Starting viewport
Stanford Student Robotics / Hands-On Robotics · quadruped
Pupper v3
Open-source educational quadruped developed through Stanford courses, with brushless motors, a Raspberry Pi 5 and a reinforcement-learning locomotion policy out of the box.
Frames · Pupper v3
4 items · credit and license on each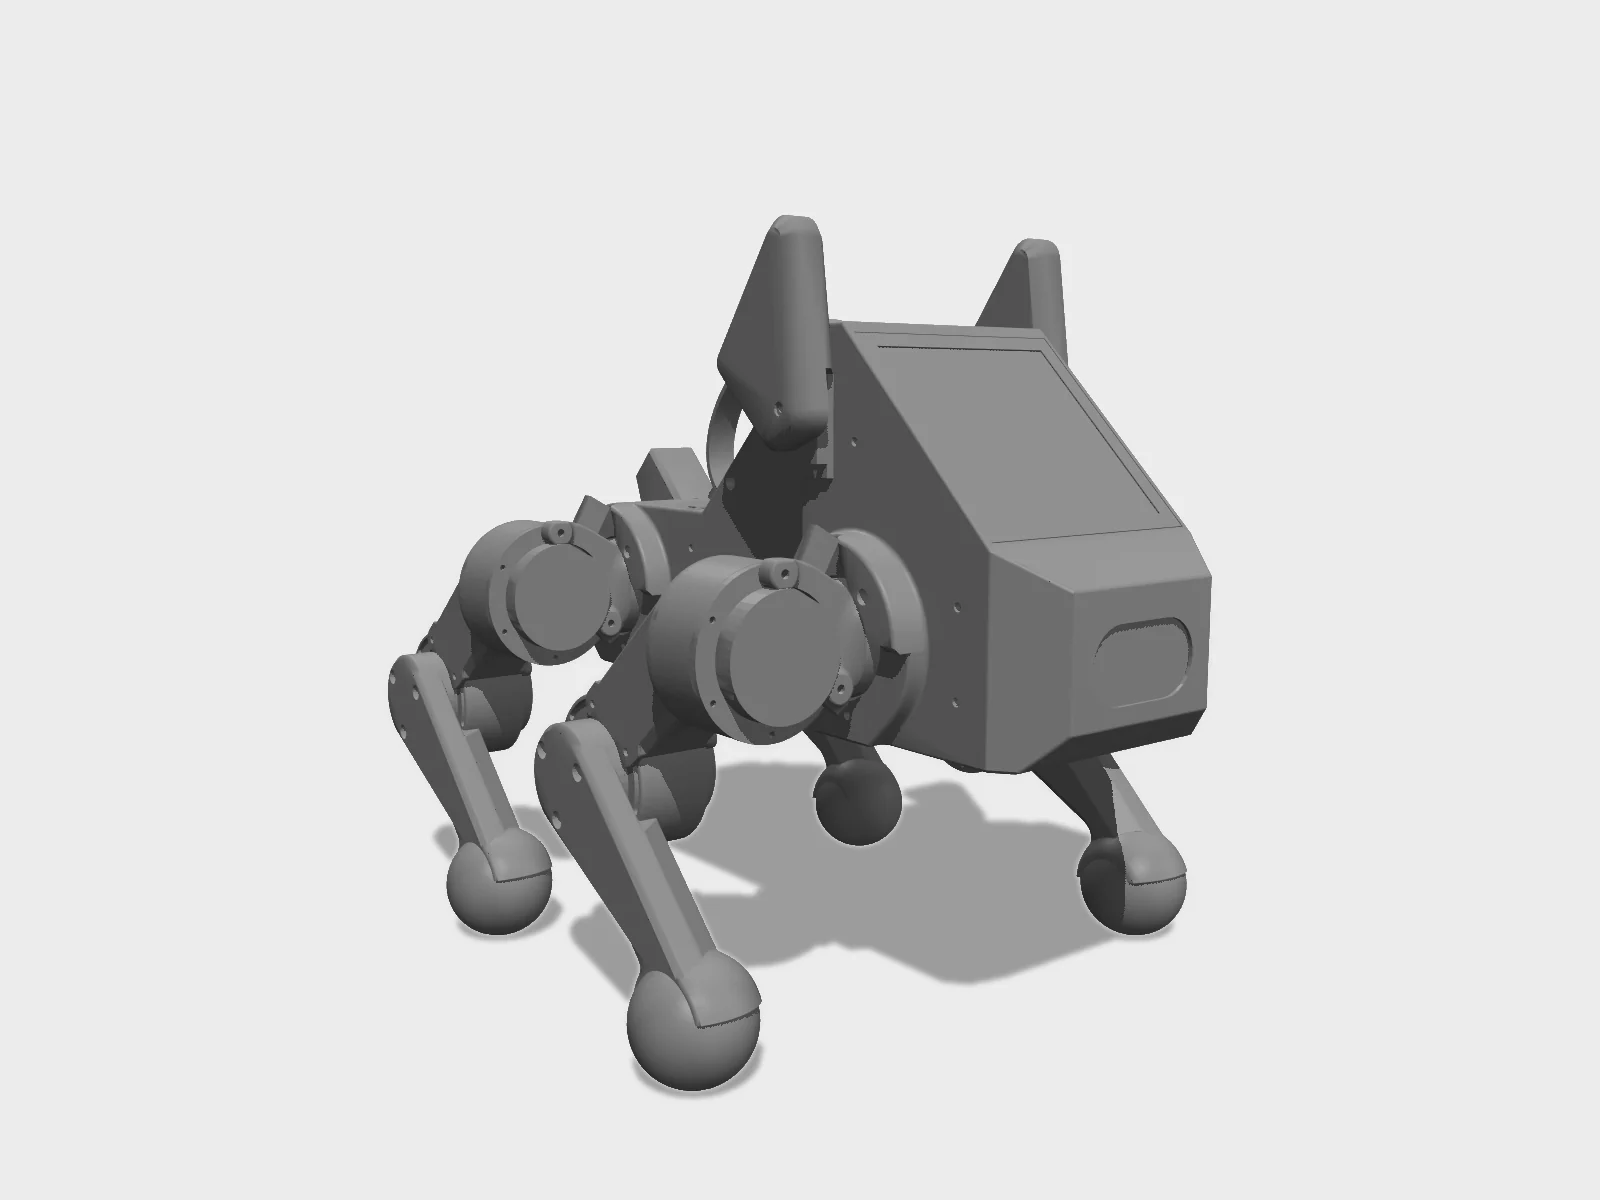
Studio render of the published MJCF, keyframe pose from the model. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from G-Levine/pupper_v3_description (MIT) · Hyperspawn render · source 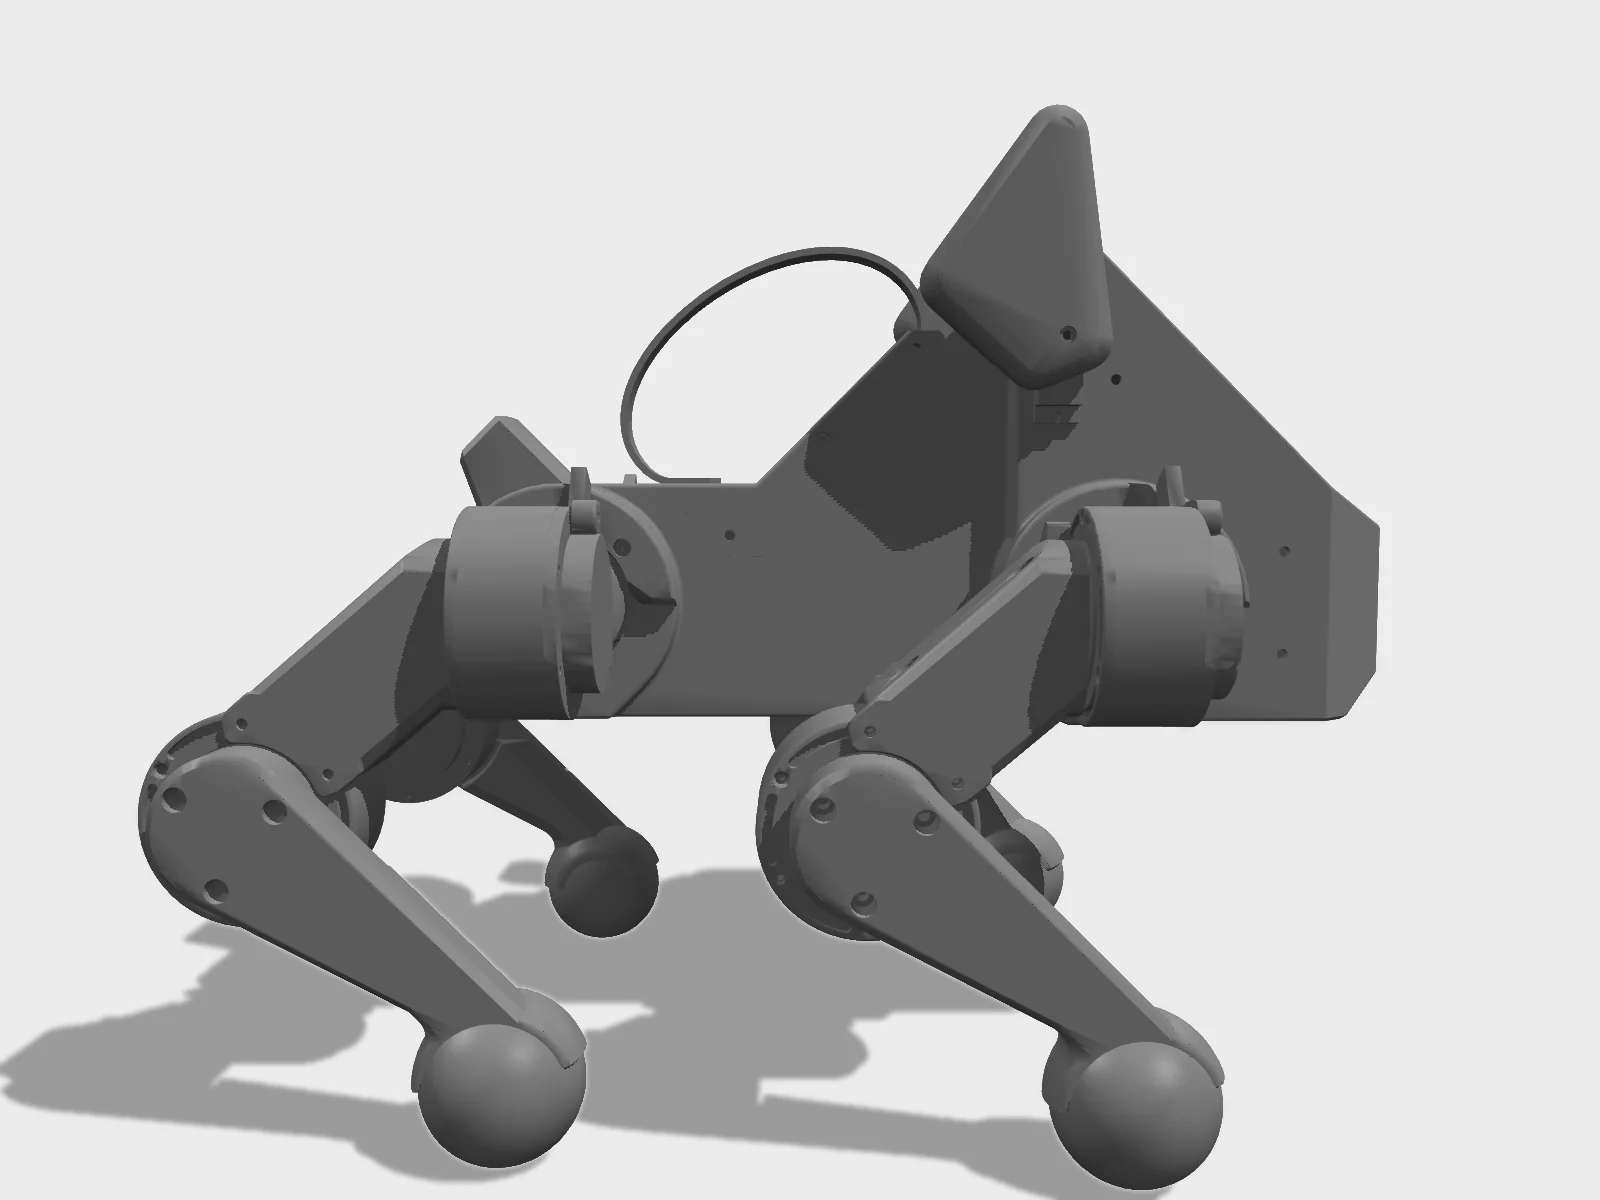
Side view of the same MJCF render, keyframe pose from the model.Rendered by Hyperspawn from G-Levine/pupper_v3_description (MIT) · Hyperspawn render · source 4 s turntable of the MJCF studio render.Rendered by Hyperspawn from G-Levine/pupper_v3_description (MIT) · Hyperspawn render · source 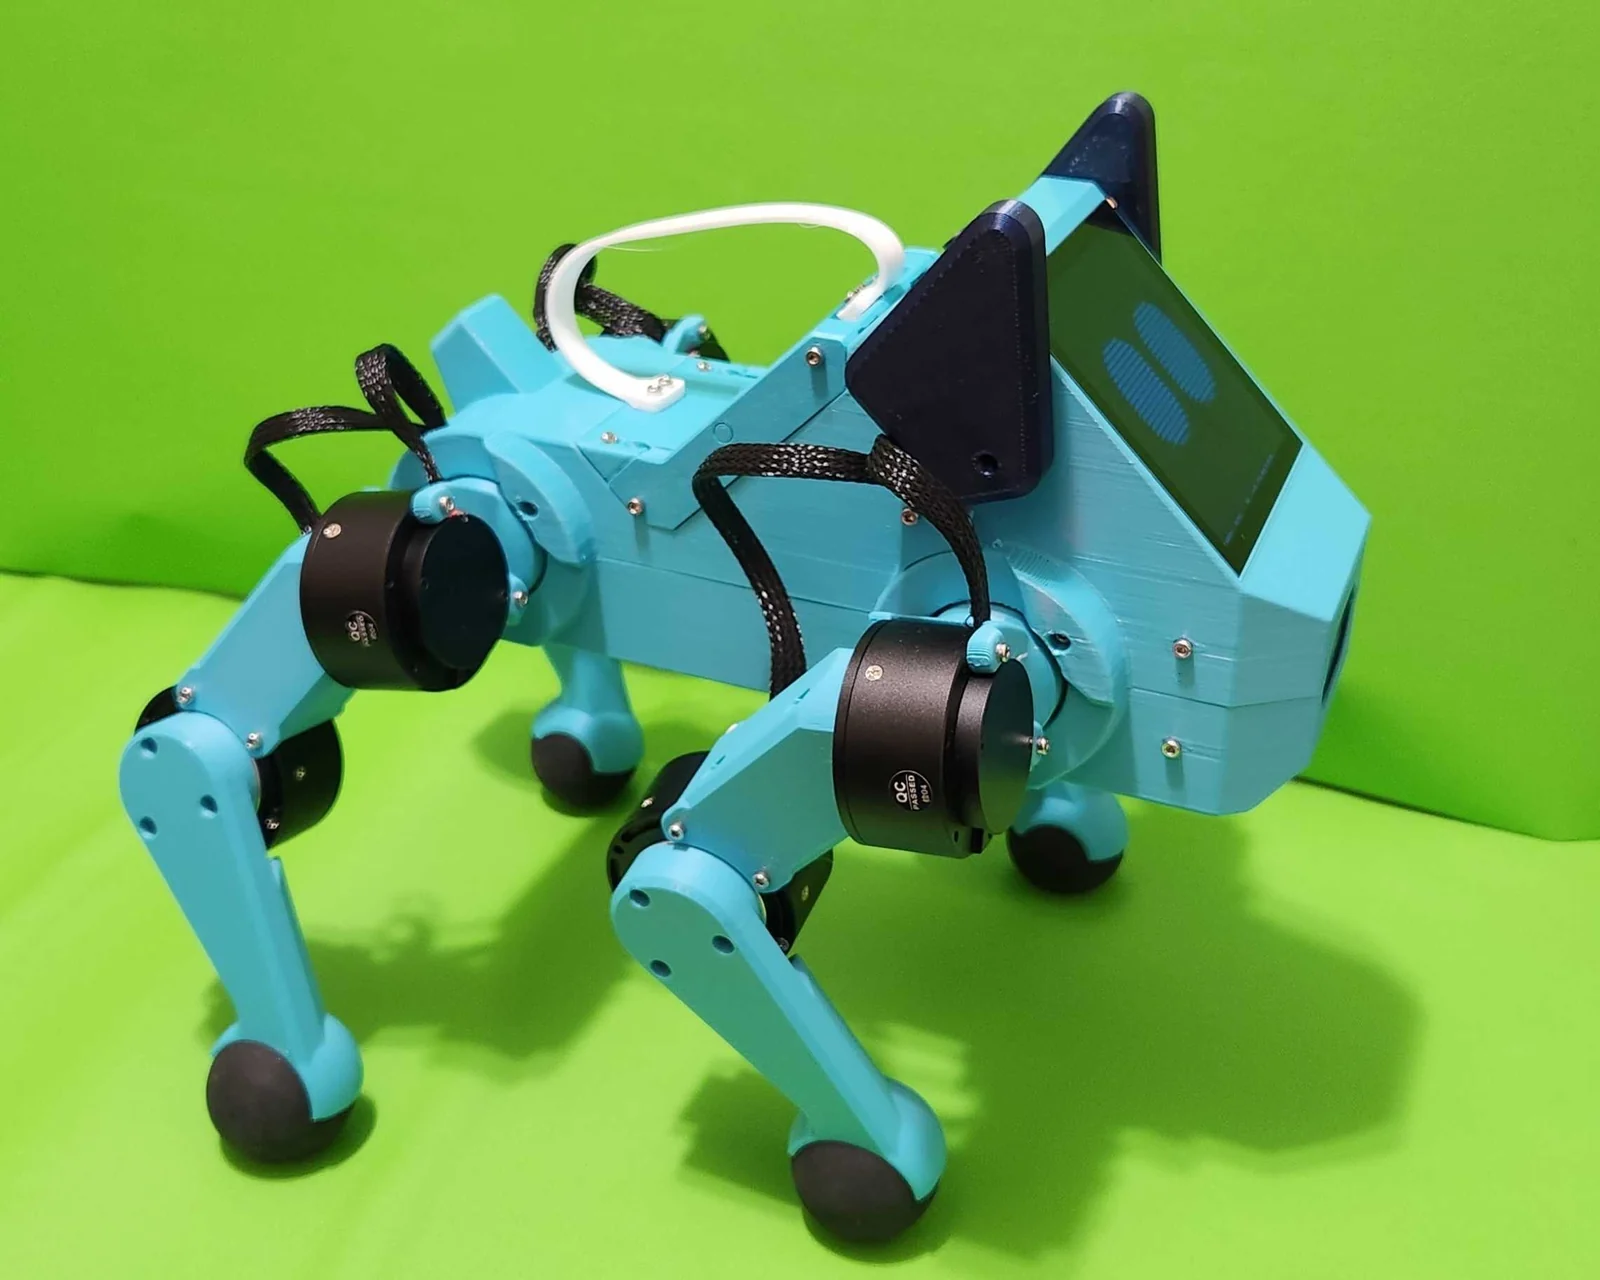
From the pupper-v3 documentation.Hands-On Robotics (pupper-v3-documentation) · AGPL-3.0 · source

Provenance
No browser-ready model packaged yet.
The description is public, but nobody has pinned a commit and checked it compiles in MuJoCo WASM. Clone it and drop the folder on the viewport above (MJCF, or URDF with STL/OBJ meshes). Files stay in your tab.
Policies listed for Pupper v3
Train on GPUs
mjlab ships no stock task for Pupper v3. The training page gives you the pinned model and the steps to write a robot config.