Starting viewport
ROBOTIS · arm
OpenMANIPULATOR-X (RM-X52-TNM)
Compact ROS-based 4-DOF arm with a 1-DOF gripper built from Dynamixel XM430 servos, sold as an educational/research manipulator.
Frames · OpenMANIPULATOR-X (RM-X52-TNM)
5 items · credit and license on each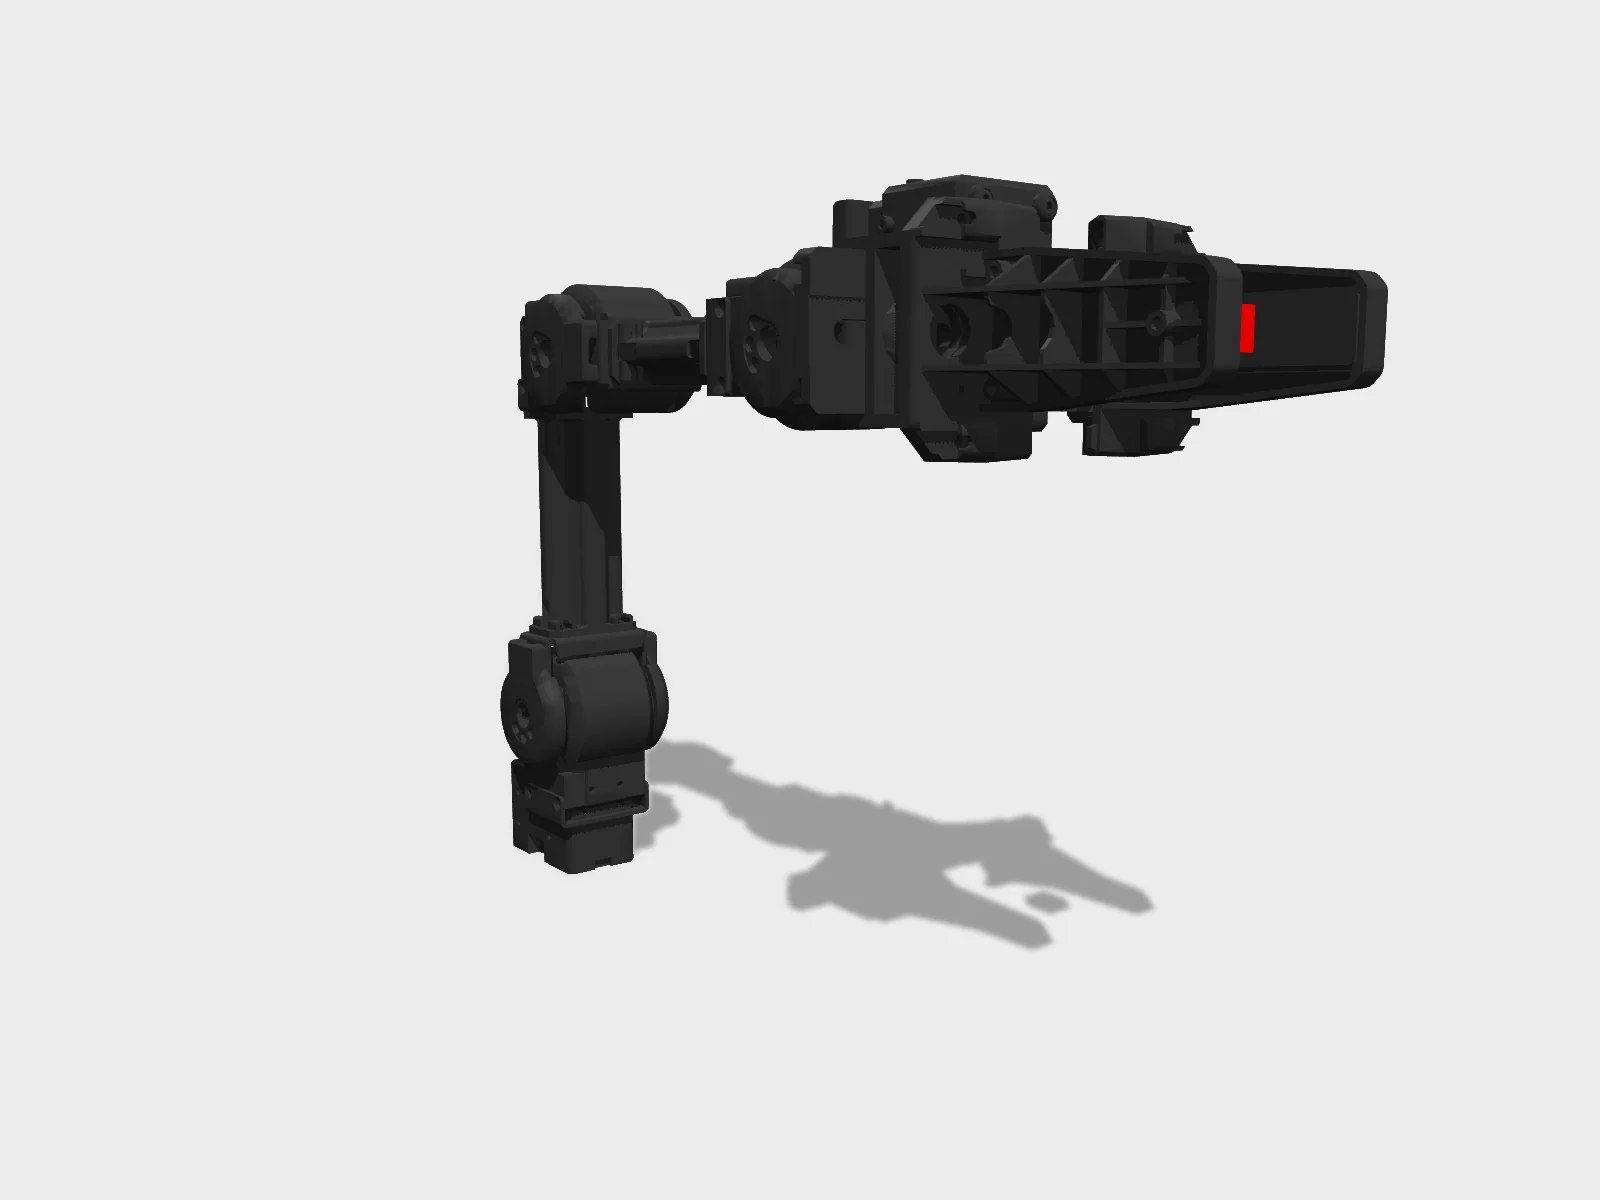
Studio render of the published URDF, the model's zero pose. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from ROBOTIS-GIT/open_manipulator (Apache-2.0) · Hyperspawn render · source 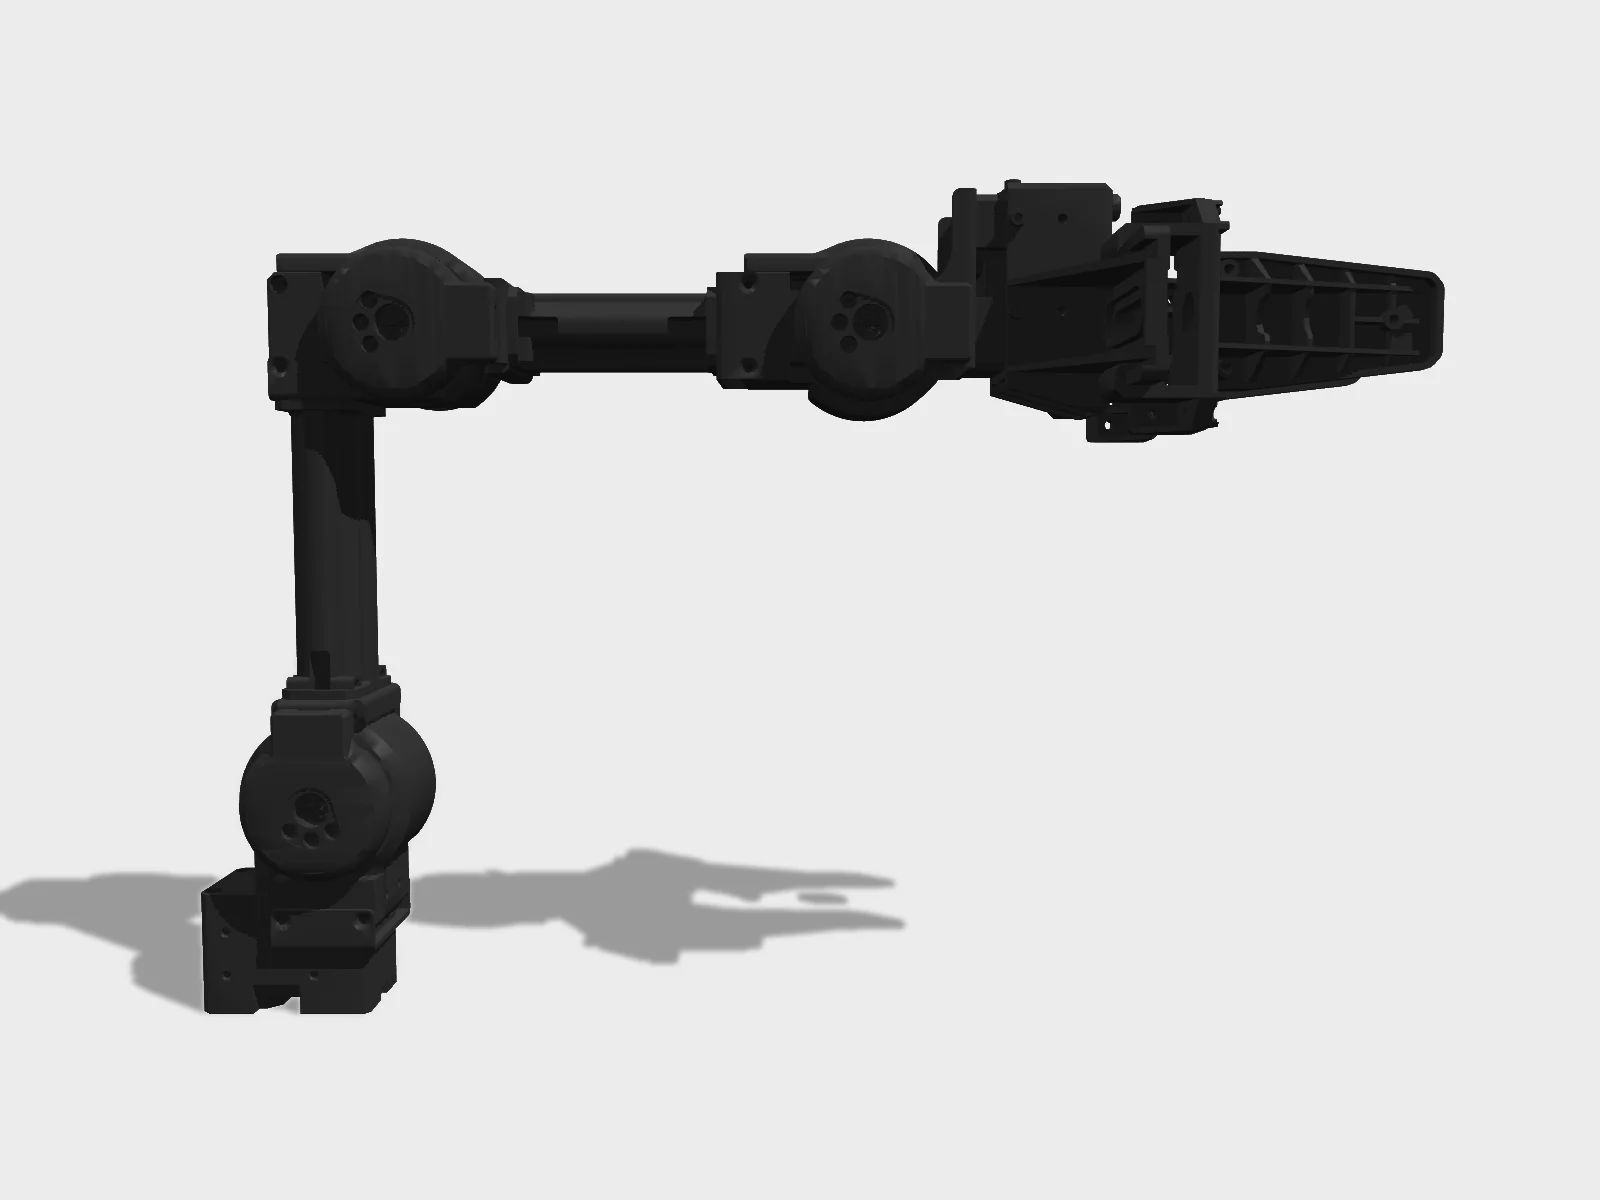
Side view of the same URDF render, the model's zero pose.Rendered by Hyperspawn from ROBOTIS-GIT/open_manipulator (Apache-2.0) · Hyperspawn render · source 4 s turntable of the URDF studio render.Rendered by Hyperspawn from ROBOTIS-GIT/open_manipulator (Apache-2.0) · Hyperspawn render · source OpenManipulator 03 : Assembling the OpenManipulatorROBOTIS OpenSourceTeam · official embed · source OpenManipulator 06 : Manipulation with ROSROBOTIS OpenSourceTeam · official embed · source
Provenance
No browser-ready model packaged yet.
The description is public, but nobody has pinned a commit and checked it compiles in MuJoCo WASM. Clone it and drop the folder on the viewport above (MJCF, or URDF with STL/OBJ meshes). Files stay in your tab.
Policies listed for OpenMANIPULATOR-X (RM-X52-TNM)
No published policy we can replay yet.
Nothing is playing a trained controller in the viewport above. What you see is a PD hold on the stand pose, computed in your tab. A policy plays here when a checkpoint is published with an obs/action contract we can reproduce exactly in MuJoCo, and it passes a 30 s walk test in the tab.
Set up a training runTrain on GPUs
mjlab ships no stock task for OpenMANIPULATOR-X (RM-X52-TNM). The training page gives you the pinned model and the steps to write a robot config.