Starting viewport
Poppy Project (Inria Flowers) · humanoid
Poppy Humanoid
Open-source 3D-printed 25-DOF humanoid (~83-85 cm, 3.5 kg) from Inria Bordeaux's Flowers lab for research, education and art.
Frames · Poppy Humanoid
7 items · credit and license on each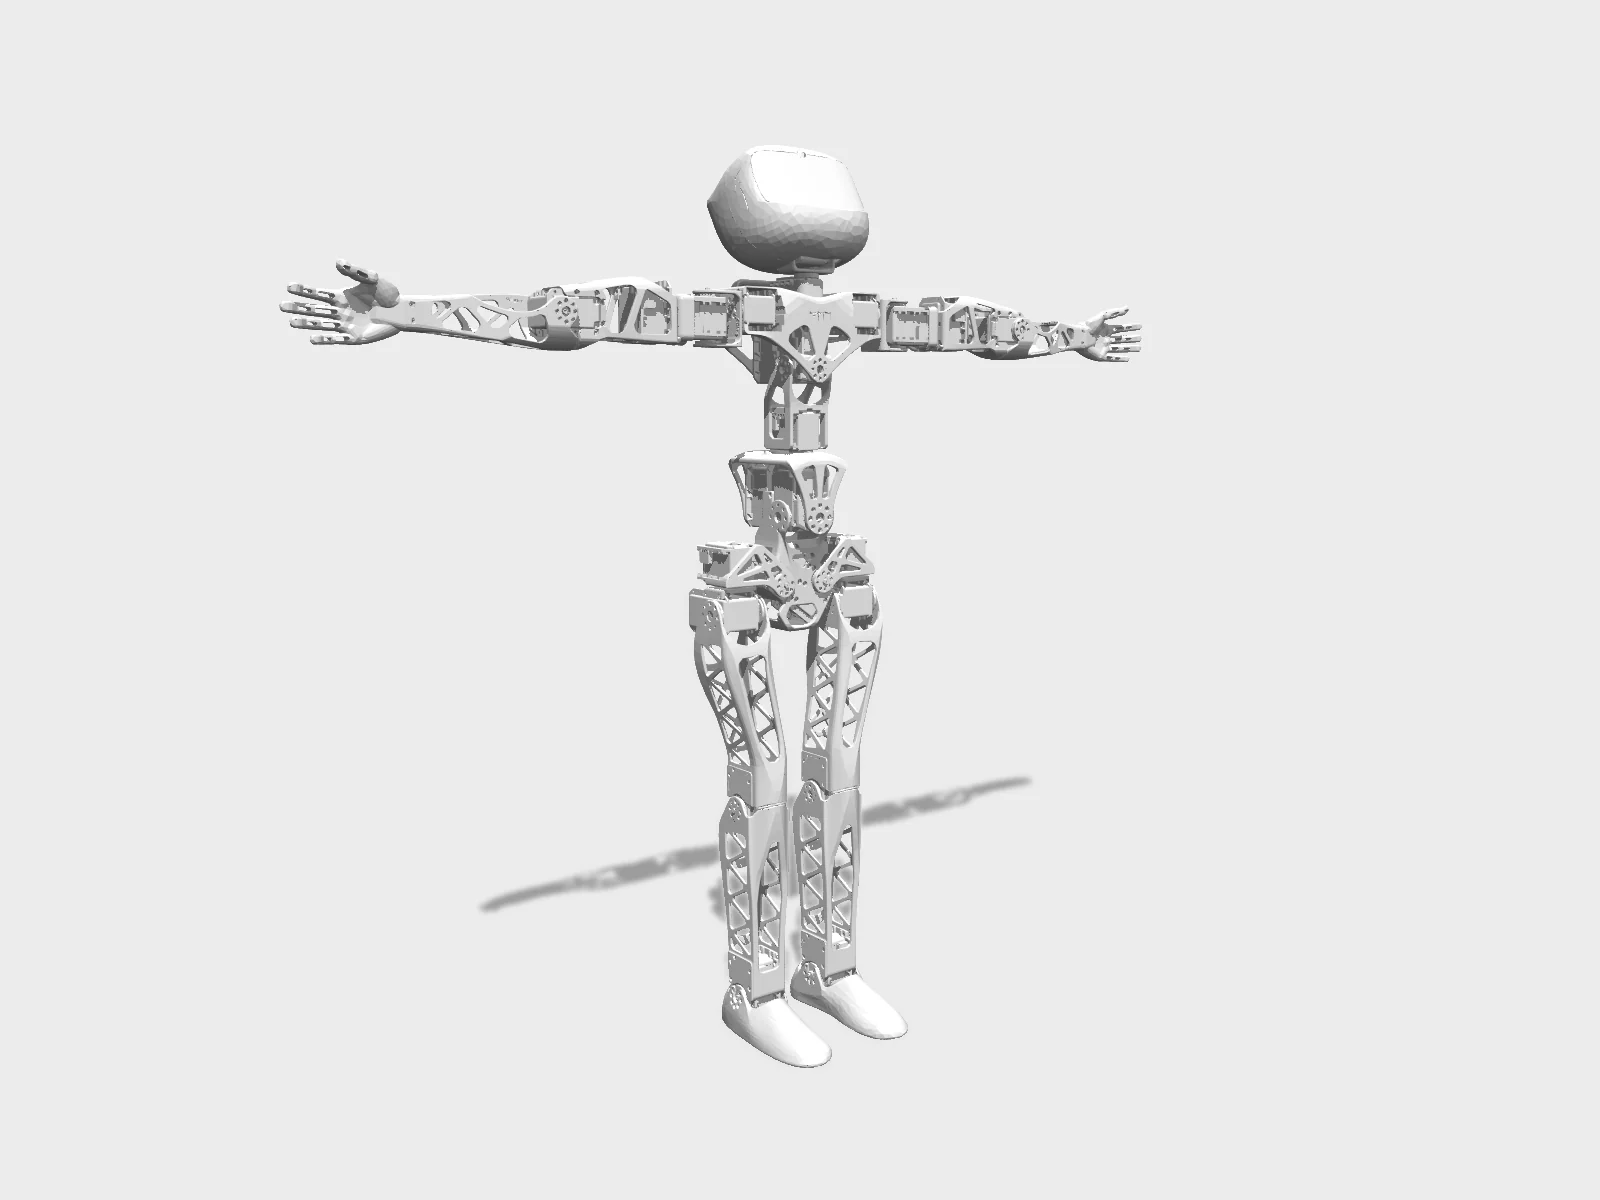
Studio render of the published URDF, the model's zero pose. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from poppy-project/poppy-humanoid (CC-BY-SA-4.0) · Hyperspawn render · source 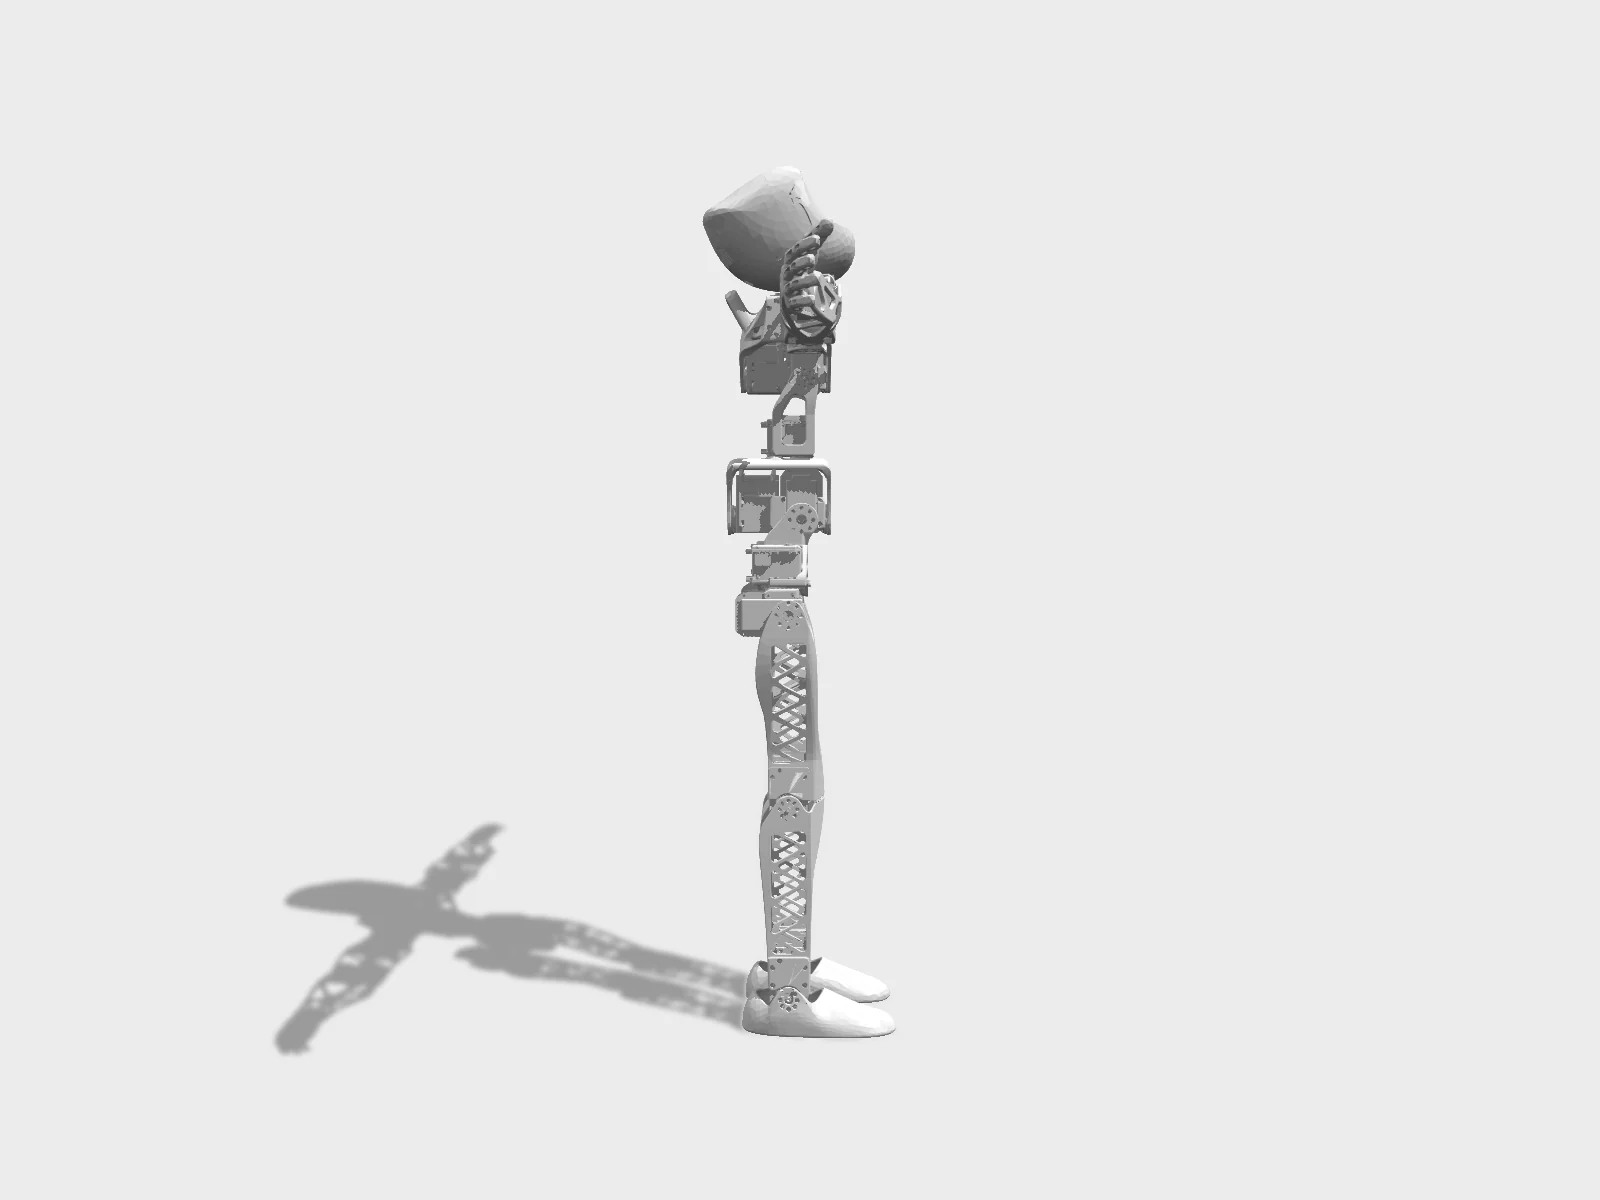
Side view of the same URDF render, the model's zero pose.Rendered by Hyperspawn from poppy-project/poppy-humanoid (CC-BY-SA-4.0) · Hyperspawn render · source 4 s turntable of the URDF studio render.Rendered by Hyperspawn from poppy-project/poppy-humanoid (CC-BY-SA-4.0) · Hyperspawn render · source 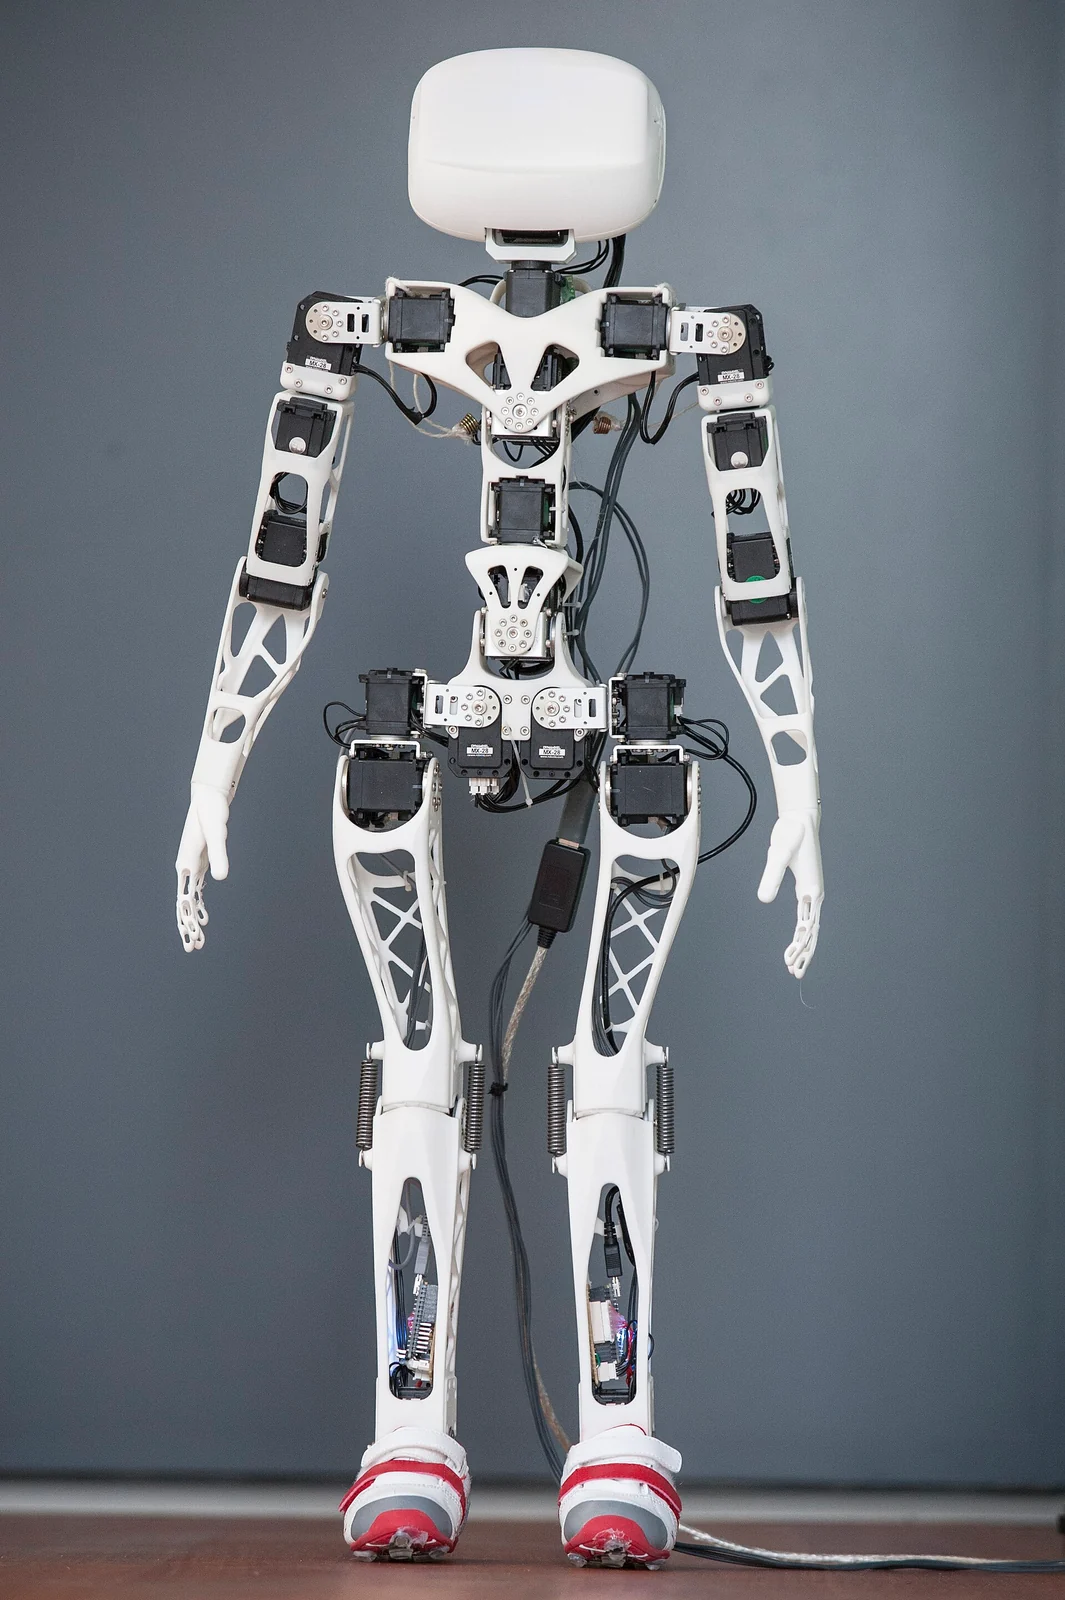
Via Wikimedia Commons (CC BY-SA 4.0).Inria / Poppy-project.org / Photo H. Raguet., via Wikimedia Commons · CC-BY-SA-4.0 · source 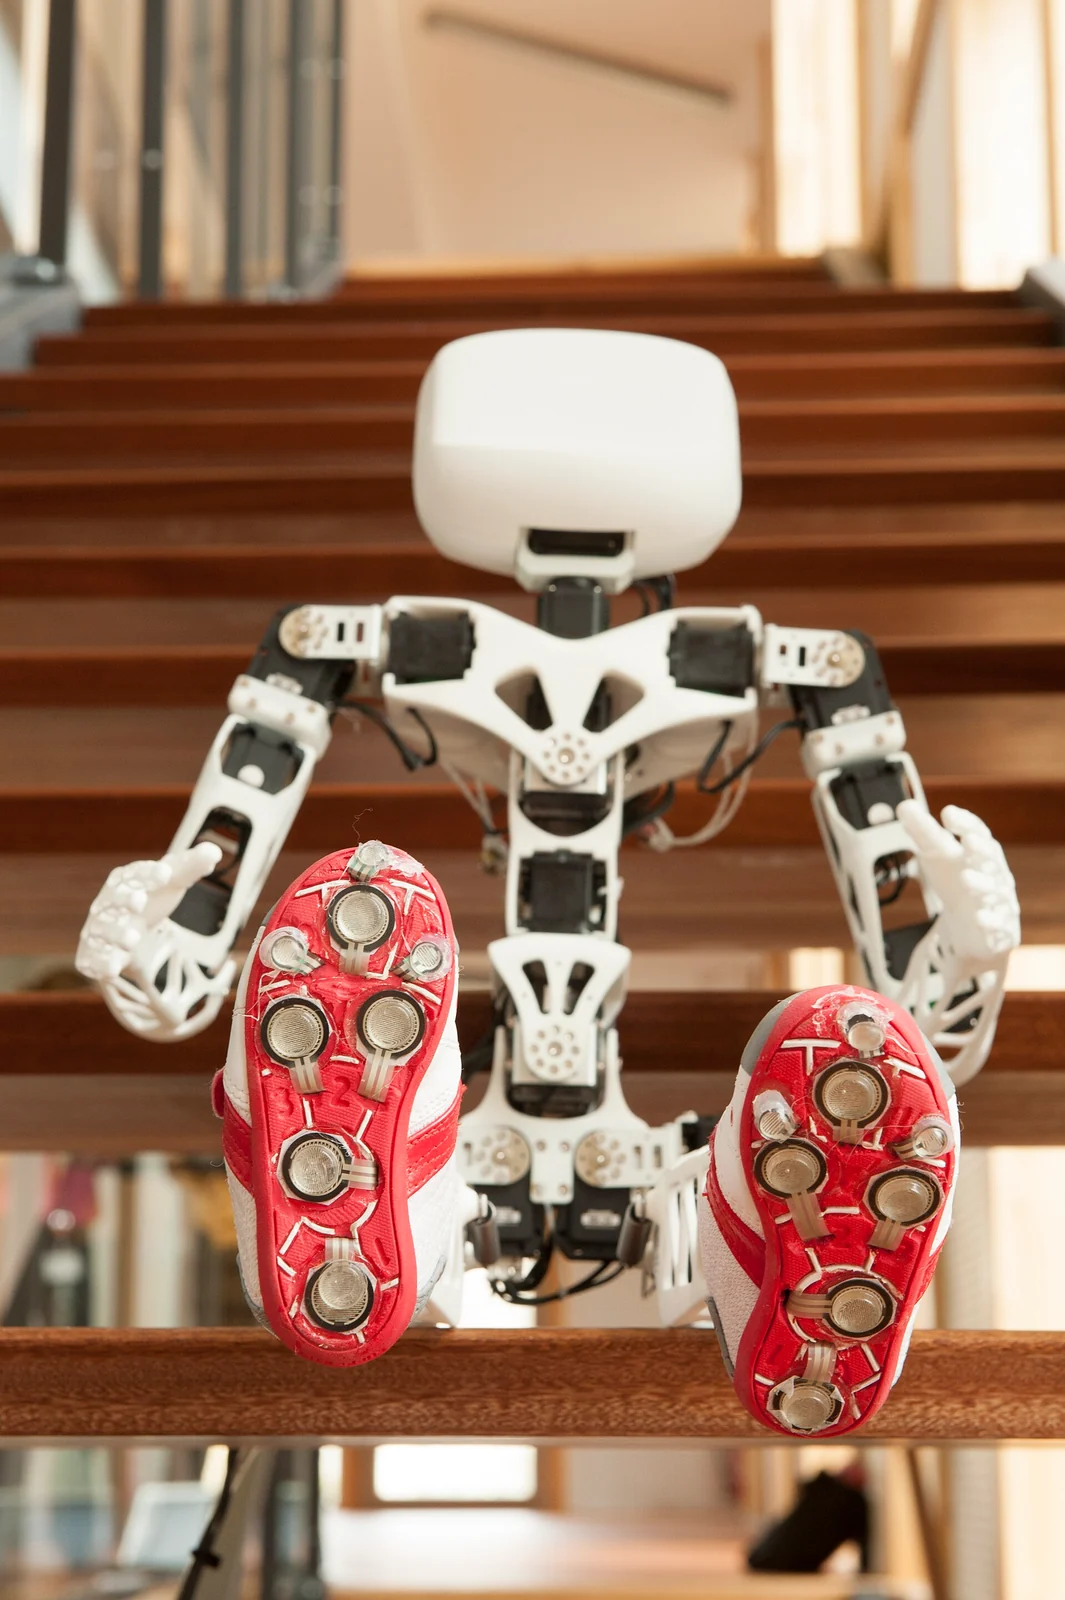
Via Wikimedia Commons (CC BY-SA 4.0).Inria / Poppy-project.org / Photo H. Raguet., via Wikimedia Commons · CC-BY-SA-4.0 · source Poppy Humanoid Beta OverviewPoppy Project · official embed · source


+1 more on humanoidrobots.systems/poppy/poppy-humanoid
Provenance
- Model
- Poppy Humanoid
- Commit
- d66c8fbd6aa3
- Entry
- hardware/URDF/robots/Poppy_Humanoid.URDF
- Files
- 27 · 224 KB, fetched from raw.githubusercontent.com, cached in your browser
- License
- none
- Engine
- MuJoCo 3.14.0, official WebAssembly build · three.js renderer
- Controller
- PD hold on the stand keyframe with an ankle-strategy tilt term; not a learned policy
- Note
- URDF only, converted by MuJoCo in the tab (collision meshes). No actuators upstream; the tab adds a position servo per joint. The repo has no license file; nothing is rehosted.
Policies listed for Poppy Humanoid
- source
Stand / sit posture (scripted primitives)
pypot primitives (Python) · not replayed in the tab
- source
Dance beat, upper-body and head idle motion (scripted)
pypot LoopPrimitive · not replayed in the tab
- source
Safety: torque limiting and temperature monitoring
pypot LoopPrimitive · not replayed in the tab
Train on GPUs
mjlab ships no stock task for Poppy Humanoid. The training page gives you the pinned model and the steps to write a robot config.