Starting viewport
PNDbotics · humanoid
Adam Lite
Full-size biped from PNDbotics, the baseline configuration of the Adam line, with 25 force-controlled QDD actuators.
Frames · Adam Lite
5 items · credit and license on each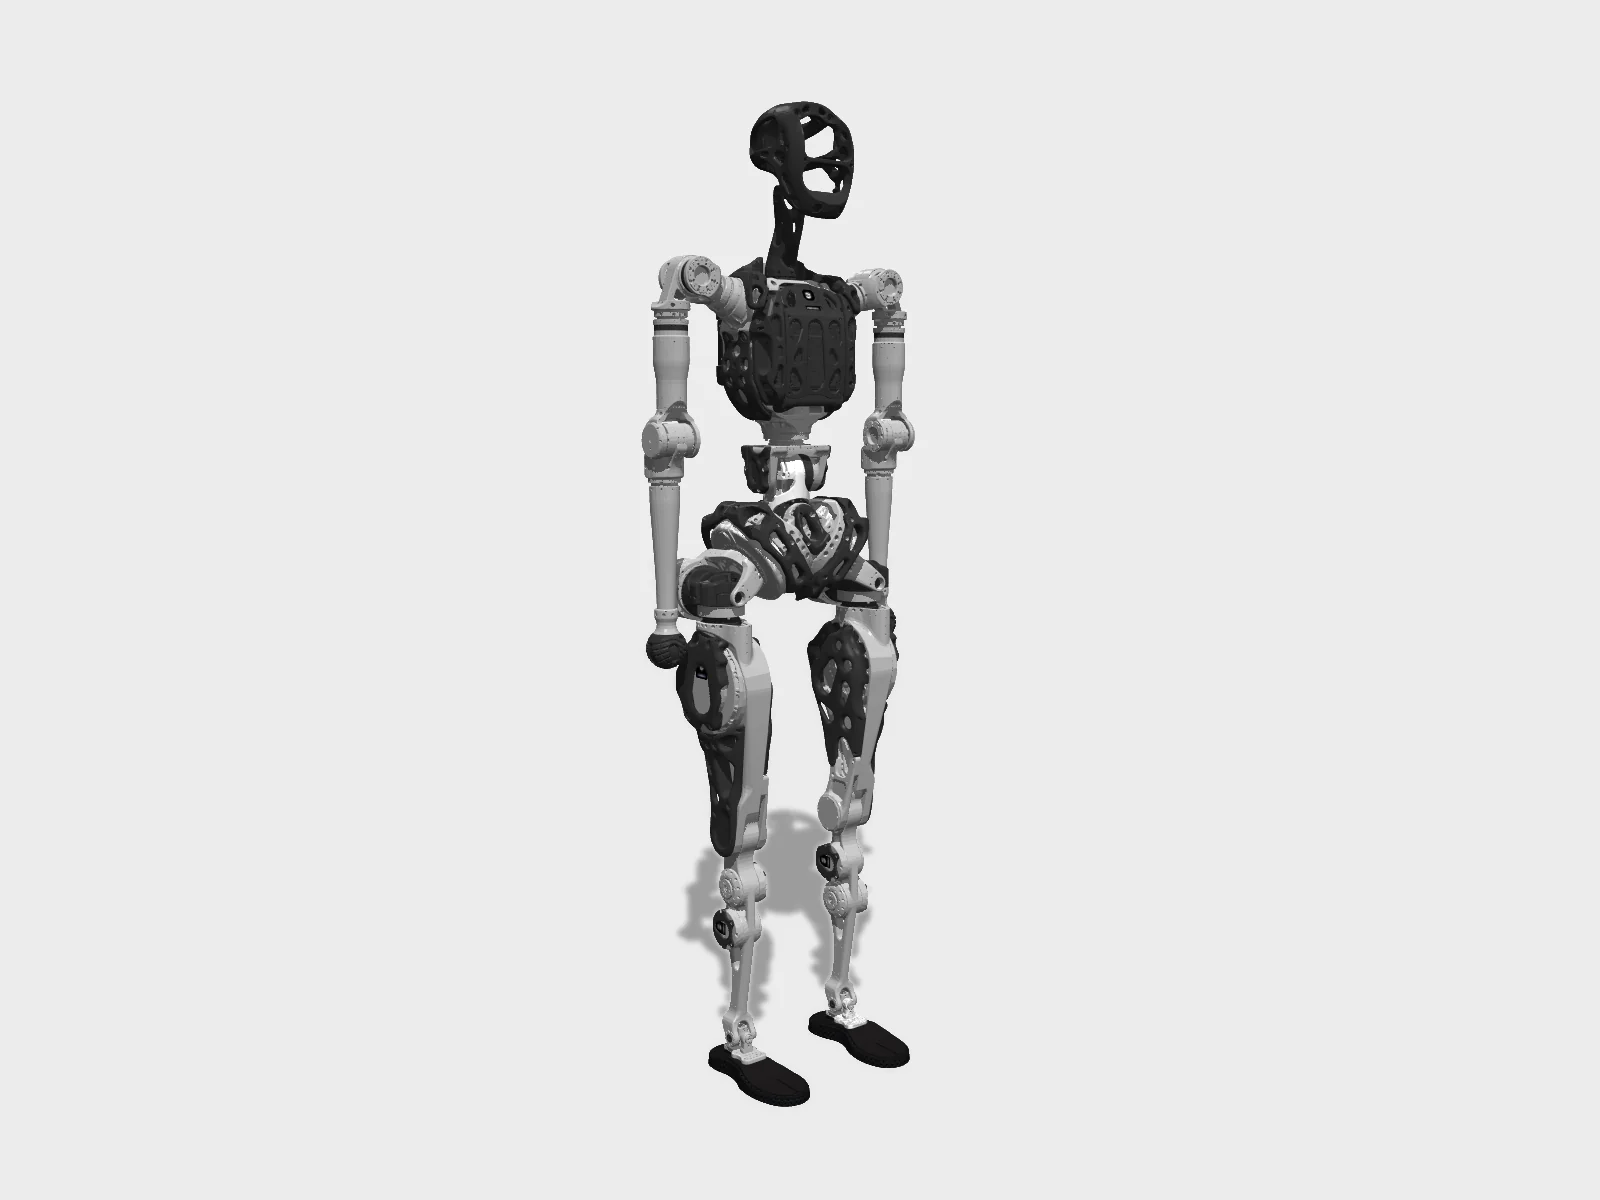
Studio render of the published MJCF, the model's zero pose. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from mujoco_menagerie/pndbotics_adam_lite (MIT) · Hyperspawn render · source 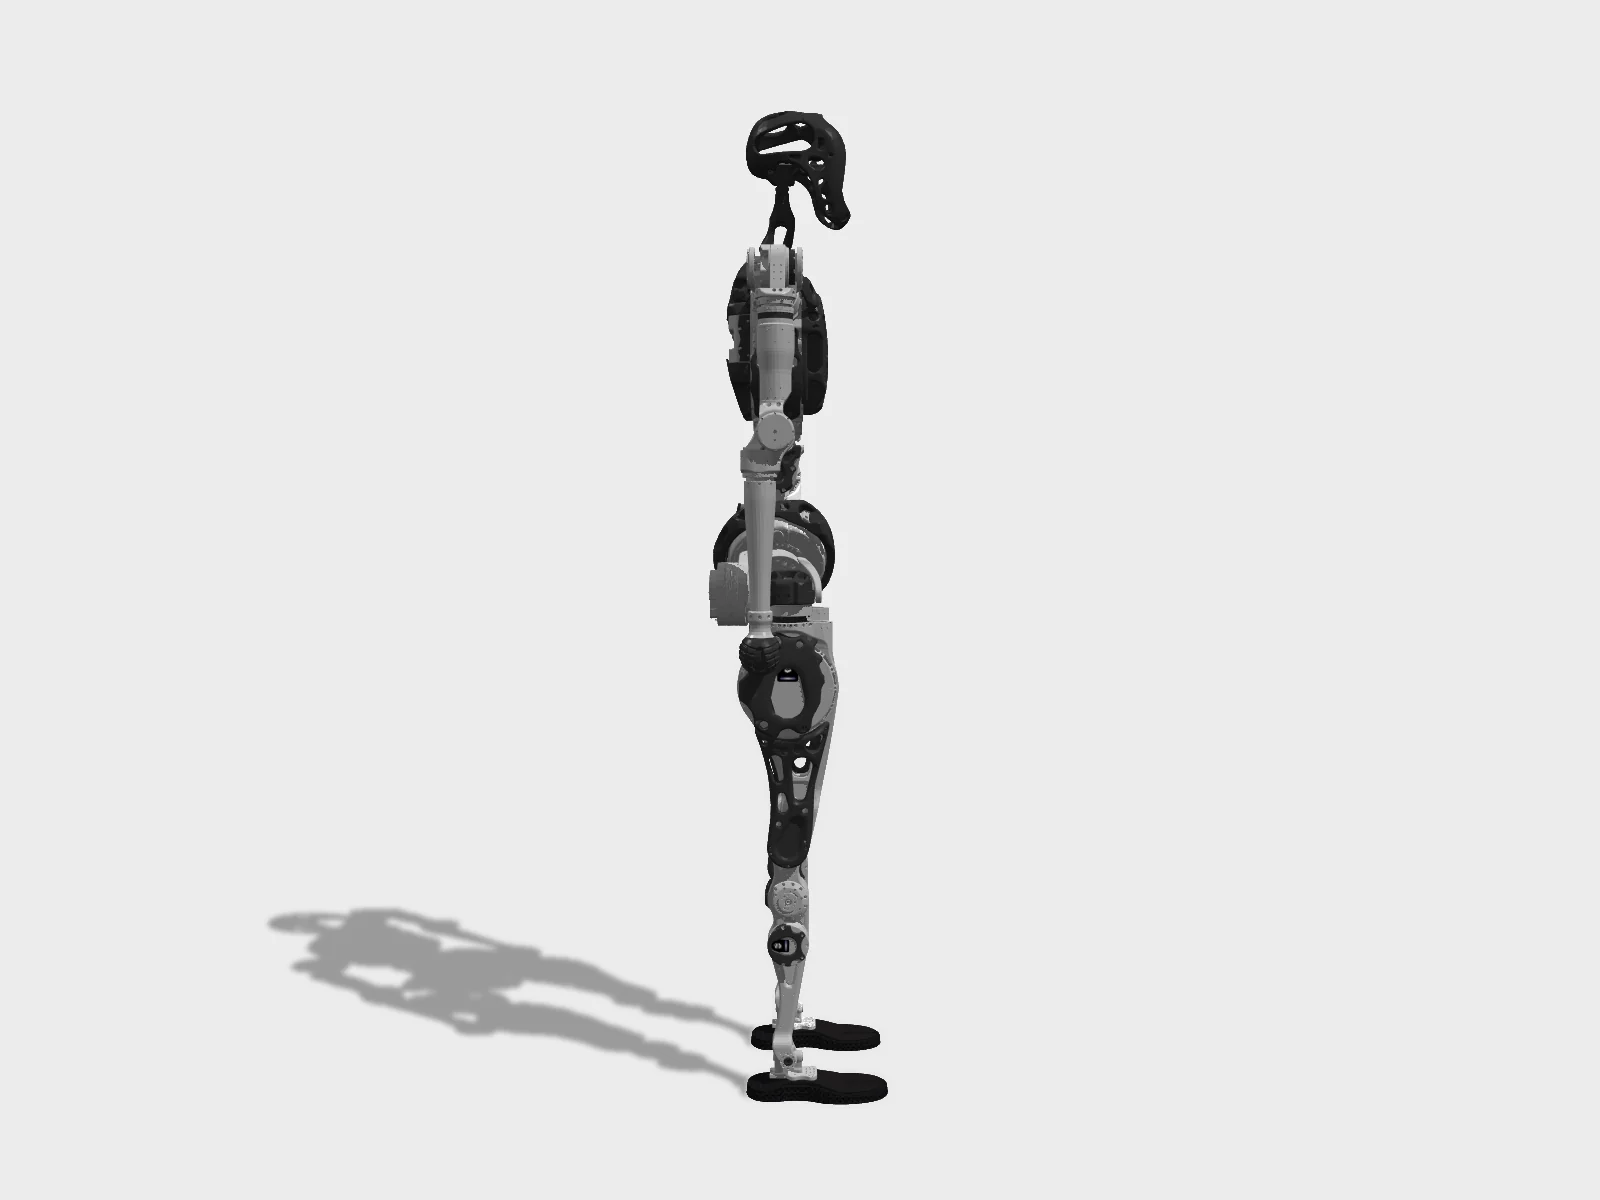
Side view of the same MJCF render, the model's zero pose.Rendered by Hyperspawn from mujoco_menagerie/pndbotics_adam_lite (MIT) · Hyperspawn render · source 4 s turntable of the MJCF studio render.Rendered by Hyperspawn from mujoco_menagerie/pndbotics_adam_lite (MIT) · Hyperspawn render · source Humanoid Robot Adam: Kill the Gap | PNDboticsPNDbotics · official embed · source Humanoid Robot Adam’s Human-Like Natural Walking ShowcasePNDbotics · official embed · source
Provenance
- Model
- PNDbotics Adam Lite
- Commit
- c96a32d28fb5
- Entry
- pndbotics_adam_lite/scene.xml
- Files
- 3 · 395 KB, fetched from raw.githubusercontent.com, cached in your browser
- License
- MIT
- Engine
- MuJoCo 3.14.0, official WebAssembly build · three.js renderer
- Controller
- PD hold on the stand keyframe with an ankle-strategy tilt term; not a learned policy
- Caveat
- Drawn with its collision shapes: the 164 MB of visual OBJ meshes are not downloaded. Physics is the published model.
- Note
- Collision shapes only: the 164 MB of visual OBJ meshes are skipped, so it draws as boxes and cylinders.
Policies listed for Adam Lite
No published policy we can replay yet.
Nothing is playing a trained controller in the viewport above. What you see is a PD hold on the stand pose, computed in your tab. A policy plays here when a checkpoint is published with an obs/action contract we can reproduce exactly in MuJoCo, and it passes a 30 s walk test in the tab.
Set up a training runTrain on GPUs
mjlab ships no stock task for Adam Lite. The training page gives you the pinned model and the steps to write a robot config.