Starting viewport
K-Scale Labs · humanoid
Z-Bot (Zeroth Bot)
Small 3D-printed open-source humanoid (~46 cm, 18 motors) from K-Scale Labs, community-developed as Zeroth Bot; sold as Z-Bot at $999 before K-Scale shut down.
Frames · Z-Bot (Zeroth Bot)
4 items · credit and license on each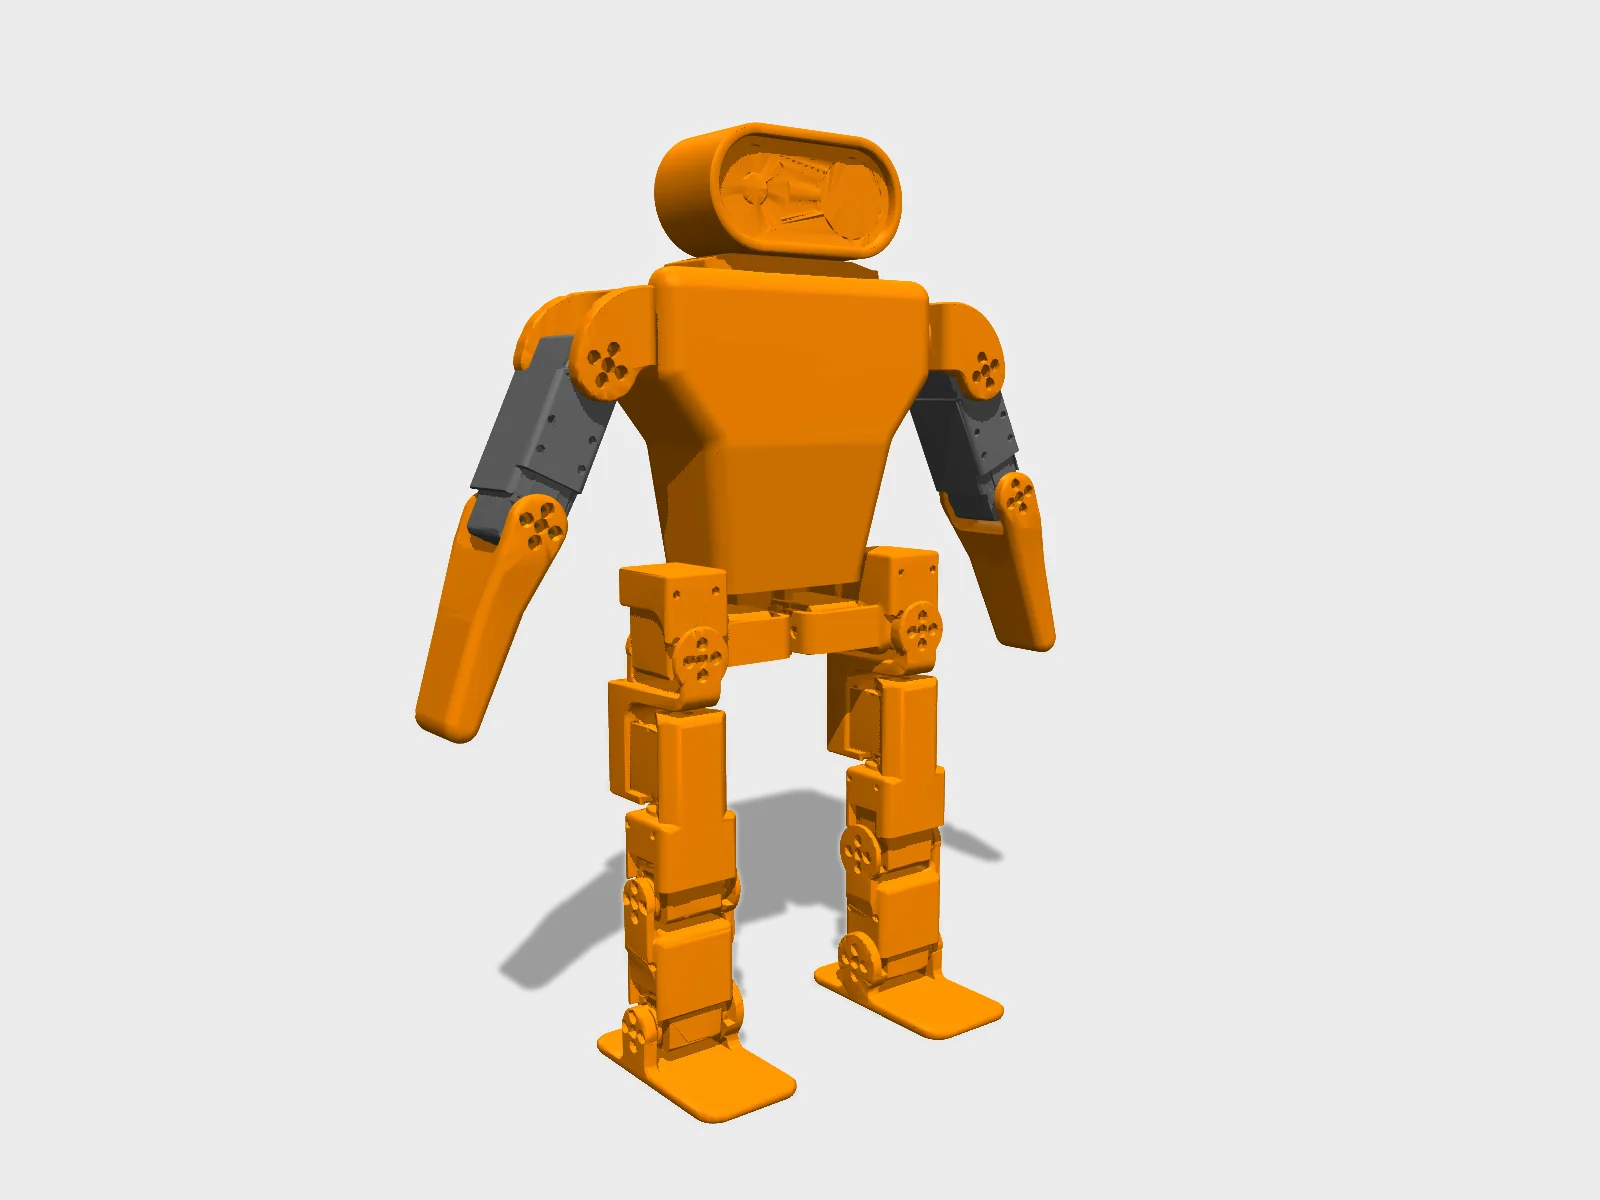
Studio render of the published URDF, the model's zero pose. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from kscalelabs/zeroth-bot (MIT) · Hyperspawn render · source 
Side view of the same URDF render, the model's zero pose.Rendered by Hyperspawn from kscalelabs/zeroth-bot (MIT) · Hyperspawn render · source 4 s turntable of the URDF studio render.Rendered by Hyperspawn from kscalelabs/zeroth-bot (MIT) · Hyperspawn render · source 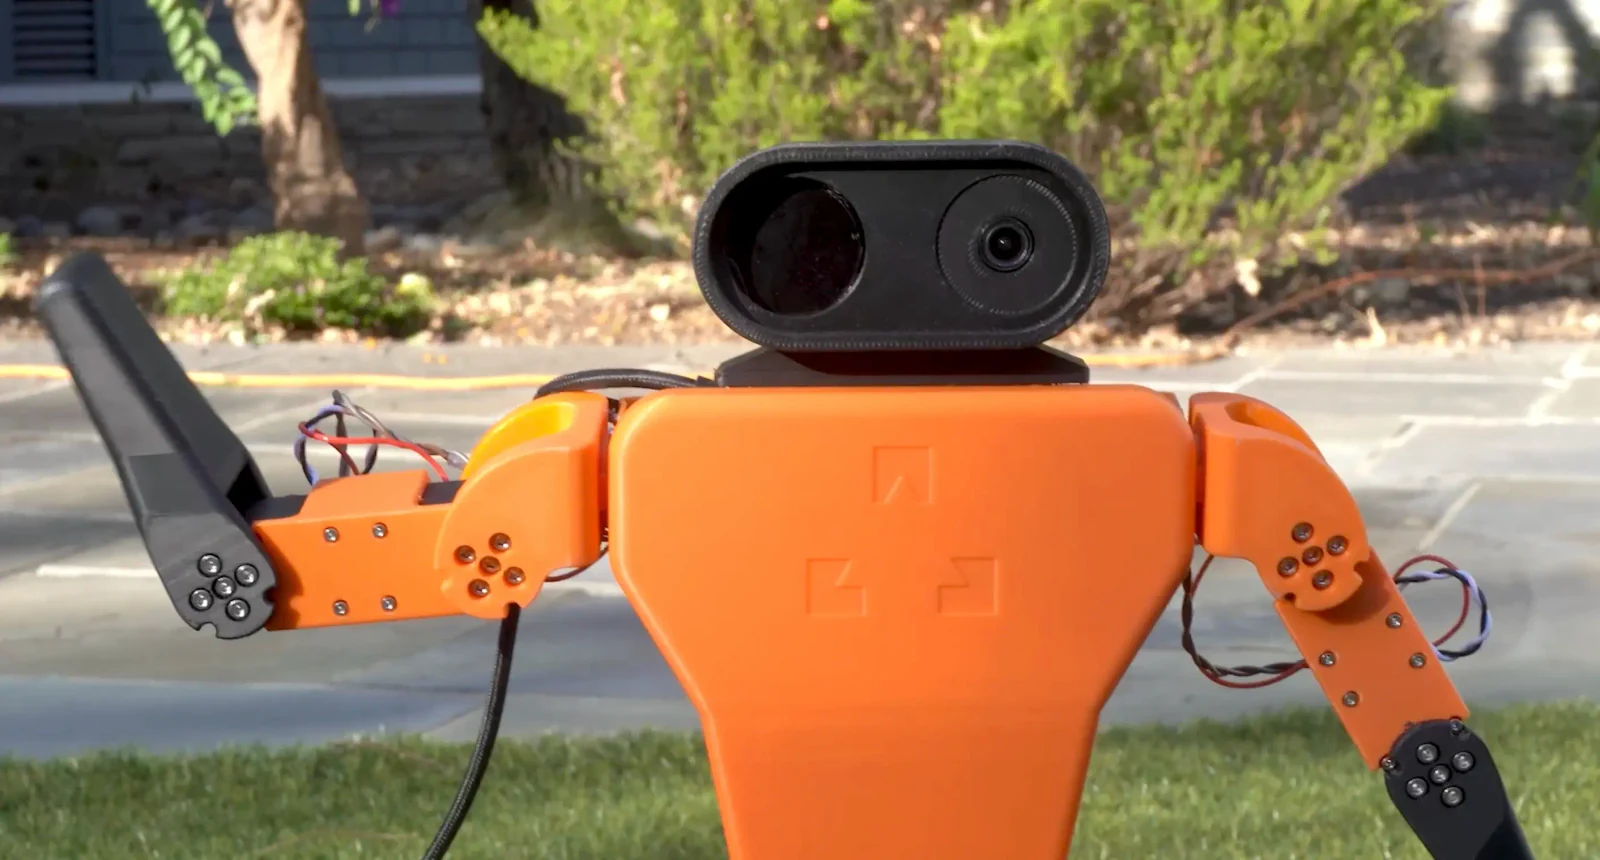
From the zeroth-bot repo.K-Scale Labs (zeroth-bot) · MIT · source

Provenance
- Model
- K-Scale Z-Bot
- Commit
- f51d6ea19b8b
- Entry
- zbot-6dof-feet/robot.mjcf
- Files
- 25 · 6.4 MB, fetched from raw.githubusercontent.com, cached in your browser
- License
- none
- Engine
- MuJoCo 3.14.0, official WebAssembly build · three.js renderer
- Controller
- PD hold on the stand keyframe with an ankle-strategy tilt term; not a learned policy
- Note
- Meshes are in Git LFS and come from media.githubusercontent.com. The repo has no license file; nothing is rehosted.
Policies listed for Z-Bot (Zeroth Bot)
- source
Z-Bot joystick/velocity walking (RL benchmark template)
ksim (JAX/MuJoCo) + kinfer · not replayed in the tab
- source
Basic Z-Bot walking policy
ksim + kinfer · not replayed in the tab
- source
Standing policy (Zeroth-01, TPU)
PyTorch -> CVITEK TPU (Milk-V) · not replayed in the tab
- source
Demo inference (Zeroth-01 first run)
Python SDK · not replayed in the tab
- source
Scripted demos: wave, salute; voice conversation
kos-zbot · not replayed in the tab
Train on GPUs
mjlab ships no stock task for Z-Bot (Zeroth Bot). The training page gives you the pinned model and the steps to write a robot config.