Starting viewport
UC Berkeley Hybrid Robotics Lab · humanoid
Berkeley Humanoid Lite
Open-source sub-$5,000 humanoid built from desktop-3D-printed cycloidal gearboxes and off-the-shelf parts; 0.8 m, 16 kg, 22 DOF.
Frames · Berkeley Humanoid Lite
4 items · credit and license on each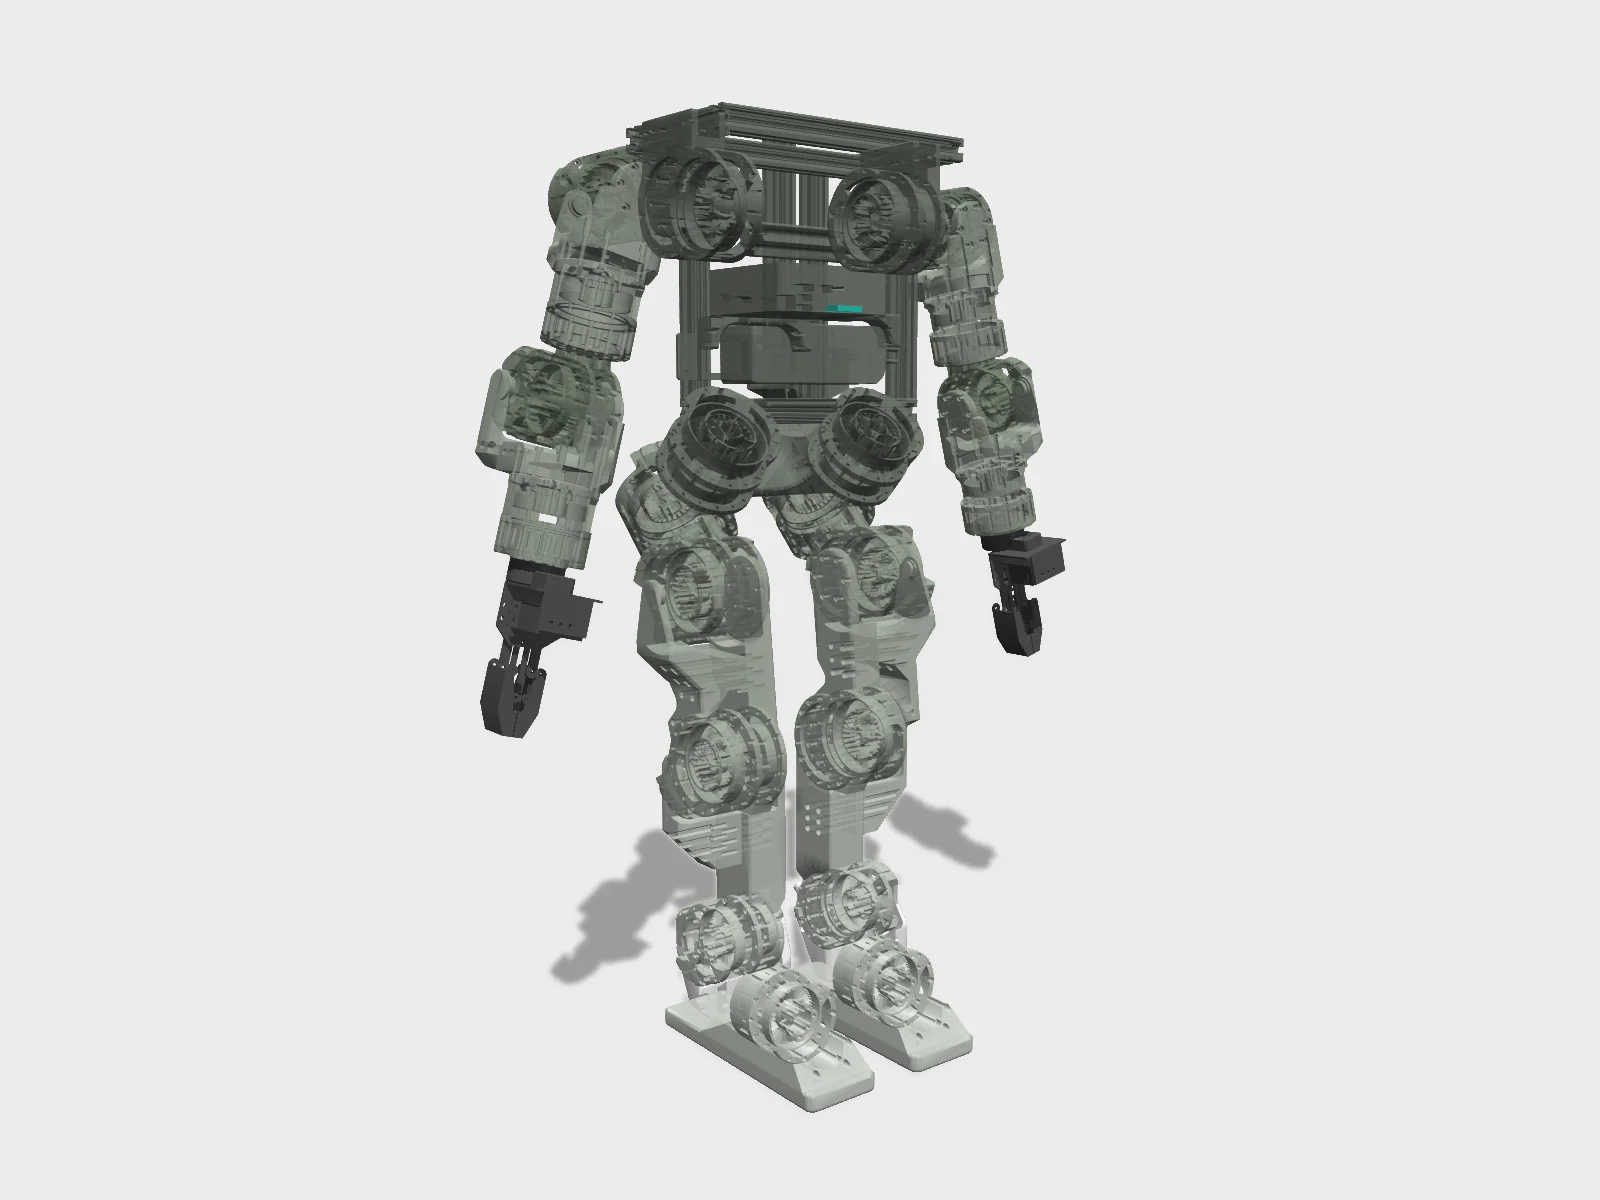
Studio render of the published URDF, the model's zero pose. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from HybridRobotics/berkeley-humanoid-lite-assets (CC-BY-SA-4.0) · Hyperspawn render · source 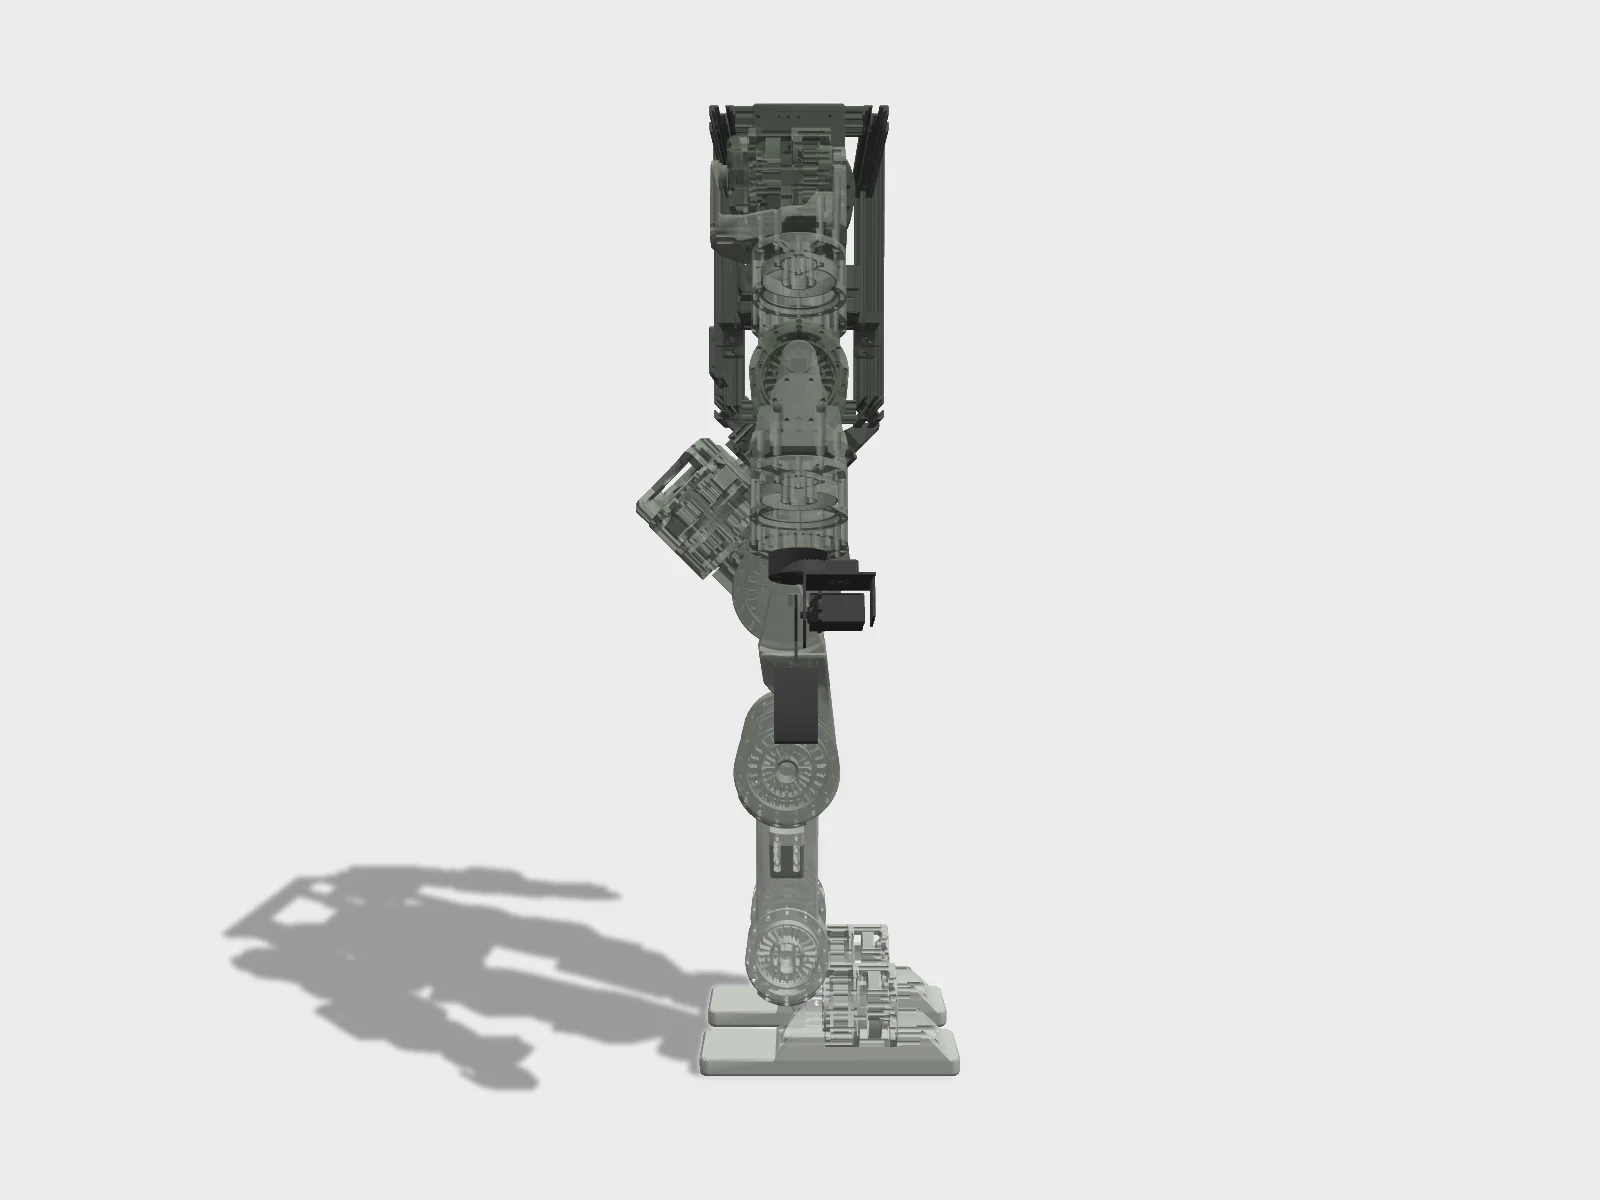
Side view of the same URDF render, the model's zero pose.Rendered by Hyperspawn from HybridRobotics/berkeley-humanoid-lite-assets (CC-BY-SA-4.0) · Hyperspawn render · source 4 s turntable of the URDF studio render.Rendered by Hyperspawn from HybridRobotics/berkeley-humanoid-lite-assets (CC-BY-SA-4.0) · Hyperspawn render · source Berkeley Humanoid Lite: An Open source, Accessible, and Customizable 3D printed Humanoid Robot.Hybrid Robotics · official embed · source
Provenance
No browser-ready model packaged yet.
The description is public, but nobody has pinned a commit and checked it compiles in MuJoCo WASM. Clone it and drop the folder on the viewport above (MJCF, or URDF with STL/OBJ meshes). Files stay in your tab.
Policies listed for Berkeley Humanoid Lite
- source
Velocity-Berkeley-Humanoid-Lite-v0 (22-DoF full humanoid velocity tracking)
Isaac Lab 2.1.0 / Isaac Sim 4.5.0 + rsl_rl PPO; ONNX deploy (policy_dt 0.04 s = 25 Hz) · not replayed in the tab yet: the MJCF meshes ship only inside a release zip, not as files we can fetch from the repo
- source
Velocity-Berkeley-Humanoid-Lite-Biped-v0 (12-DoF legs only)
Isaac Lab + rsl_rl PPO; ONNX (policy_dt 0.02 s = 50 Hz); also policy_biped_25hz_a/b.onnx · not replayed in the tab yet: the MJCF meshes ship only inside a release zip, not as files we can fetch from the repo
- source
Humanoid legs-only policy
Isaac Lab + rsl_rl; ONNX · not replayed in the tab yet: the MJCF meshes ship only inside a release zip, not as files we can fetch from the repo
- source
Video demo policy
Isaac Lab + rsl_rl; ONNX · not replayed in the tab yet: the MJCF meshes ship only inside a release zip, not as files we can fetch from the repo
- source
Sim2sim validation in MuJoCo
MuJoCo · not replayed in the tab yet: the MJCF meshes ship only inside a release zip, not as files we can fetch from the repo
- source
VR teleoperation of arms (SteamVR bridge)
SteamVR-Bridge (Windows) + IK solver · not replayed in the tab yet: the MJCF meshes ship only inside a release zip, not as files we can fetch from the repo
Train on GPUs
mjlab ships no stock task for Berkeley Humanoid Lite. The training page gives you the pinned model and the steps to write a robot config.